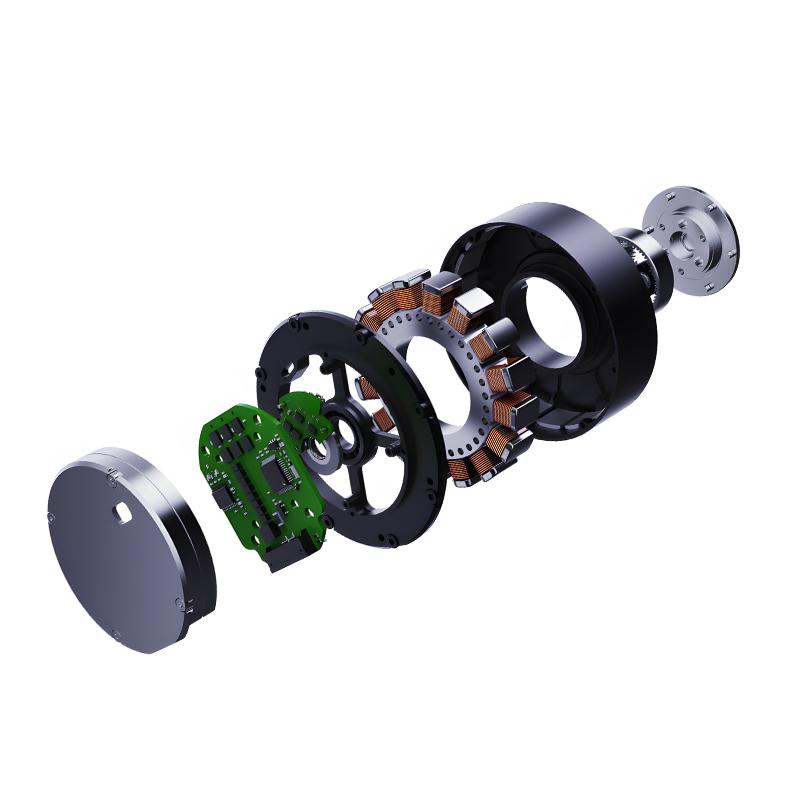
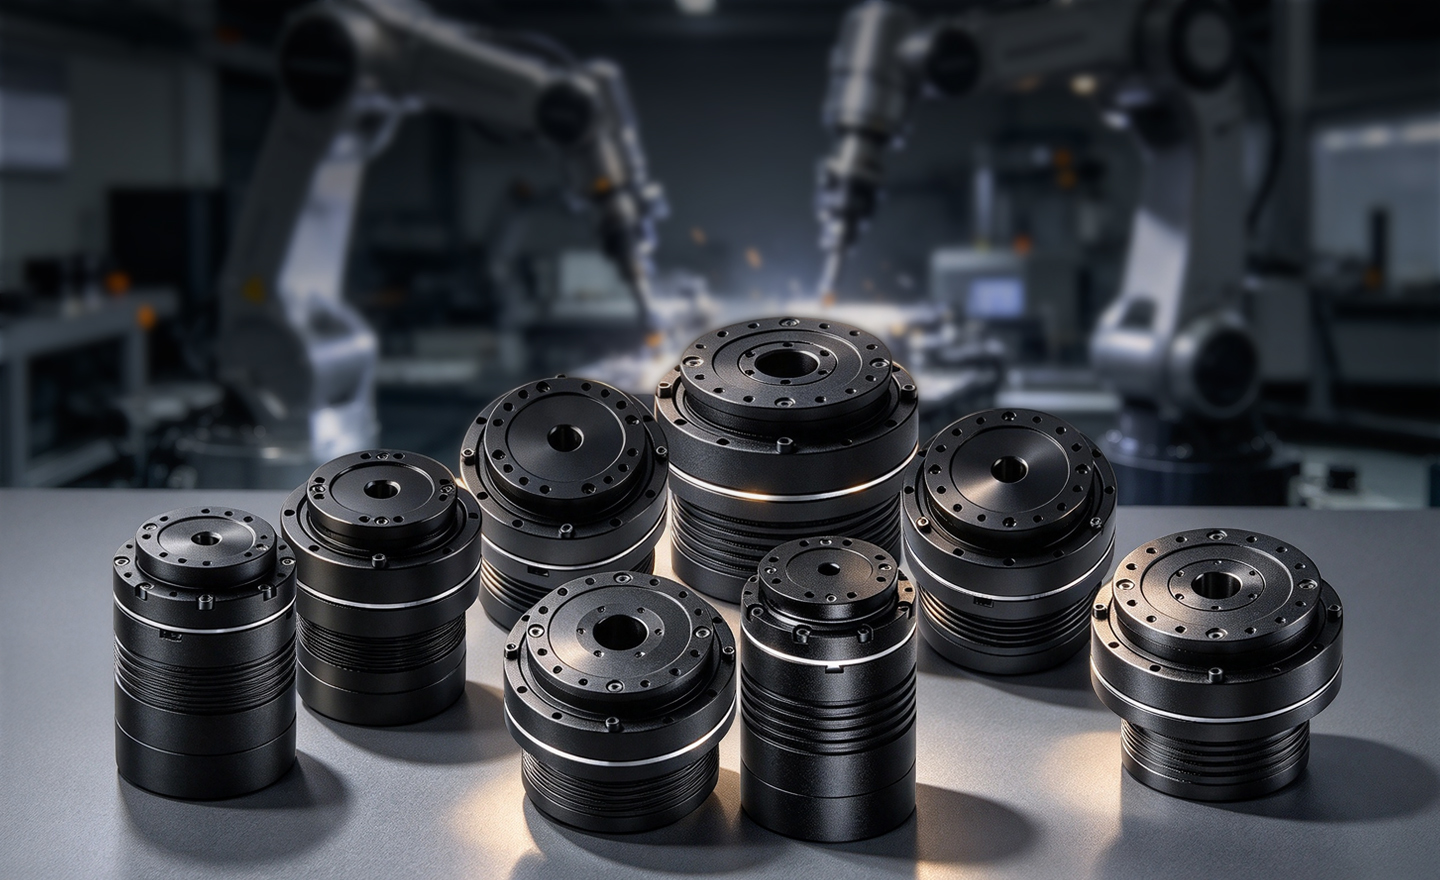
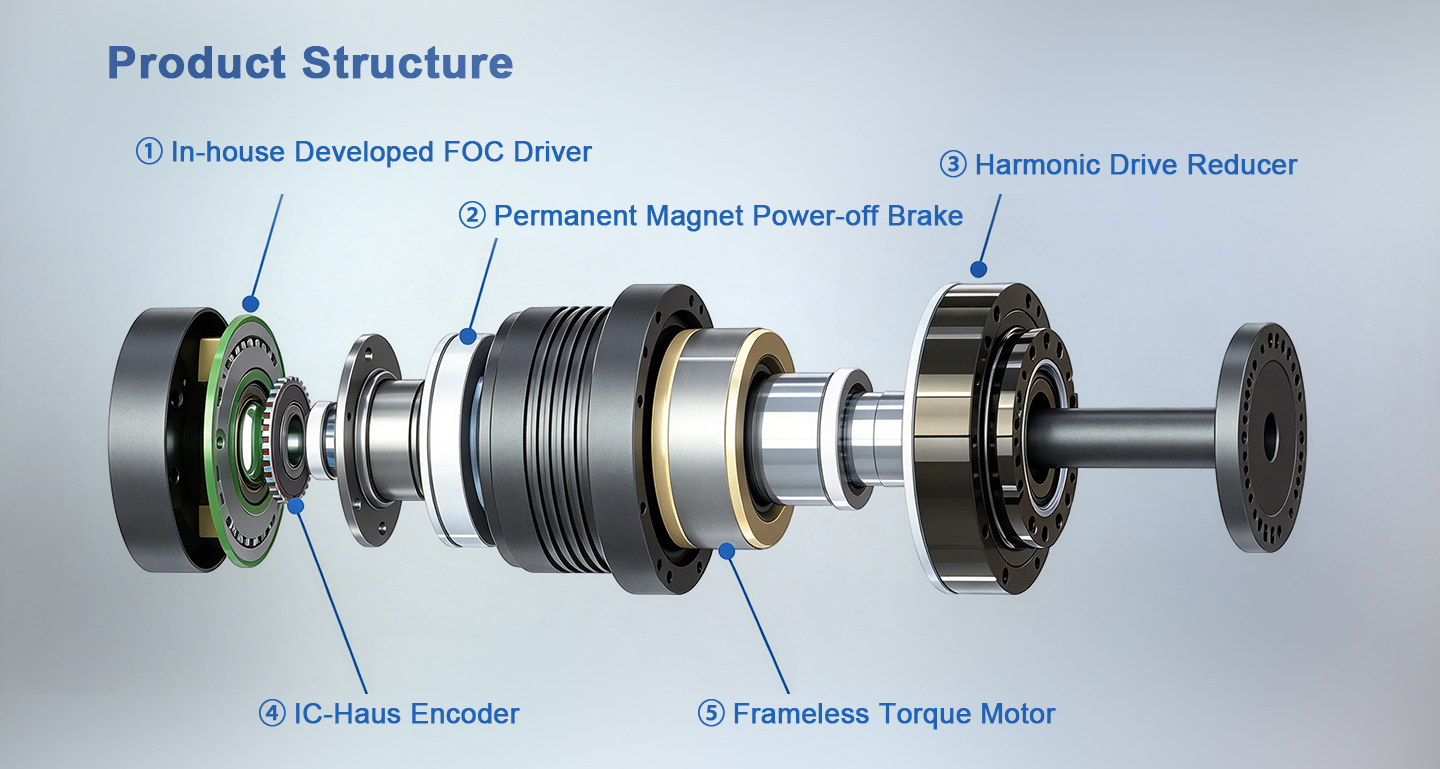
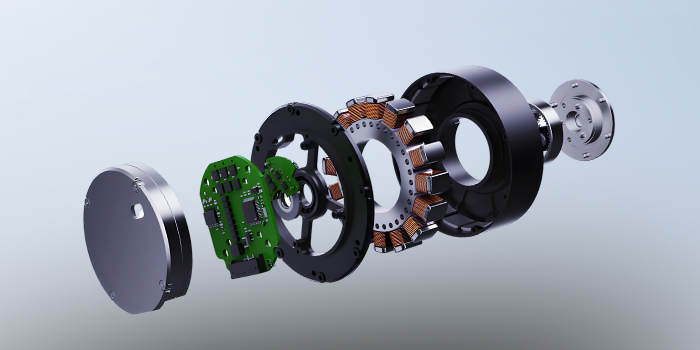
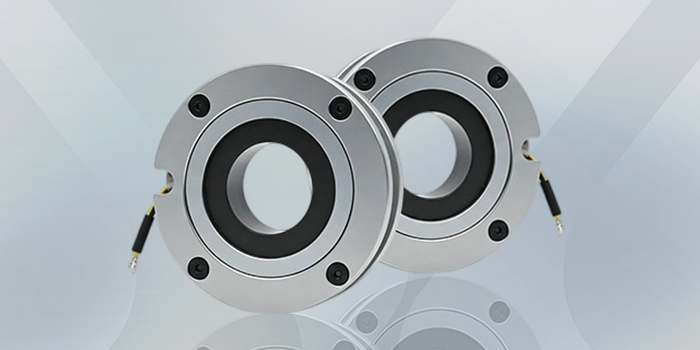
The HX-H Series is a compact integrated robot joint actuator combining a precision harmonic reducer, a frameless torque motor, an in-house developed FOC servo drive, and dual encoders. An optional permanent magnet power-off brake provides joint holding when power is removed.
Rated Torque :1.8–382 Nm
Start-Stop Peak Torque:Up to 841 Nm
Maximum Output Peak Speed:118 rpm
Supply Voltage: 24–48 V DC
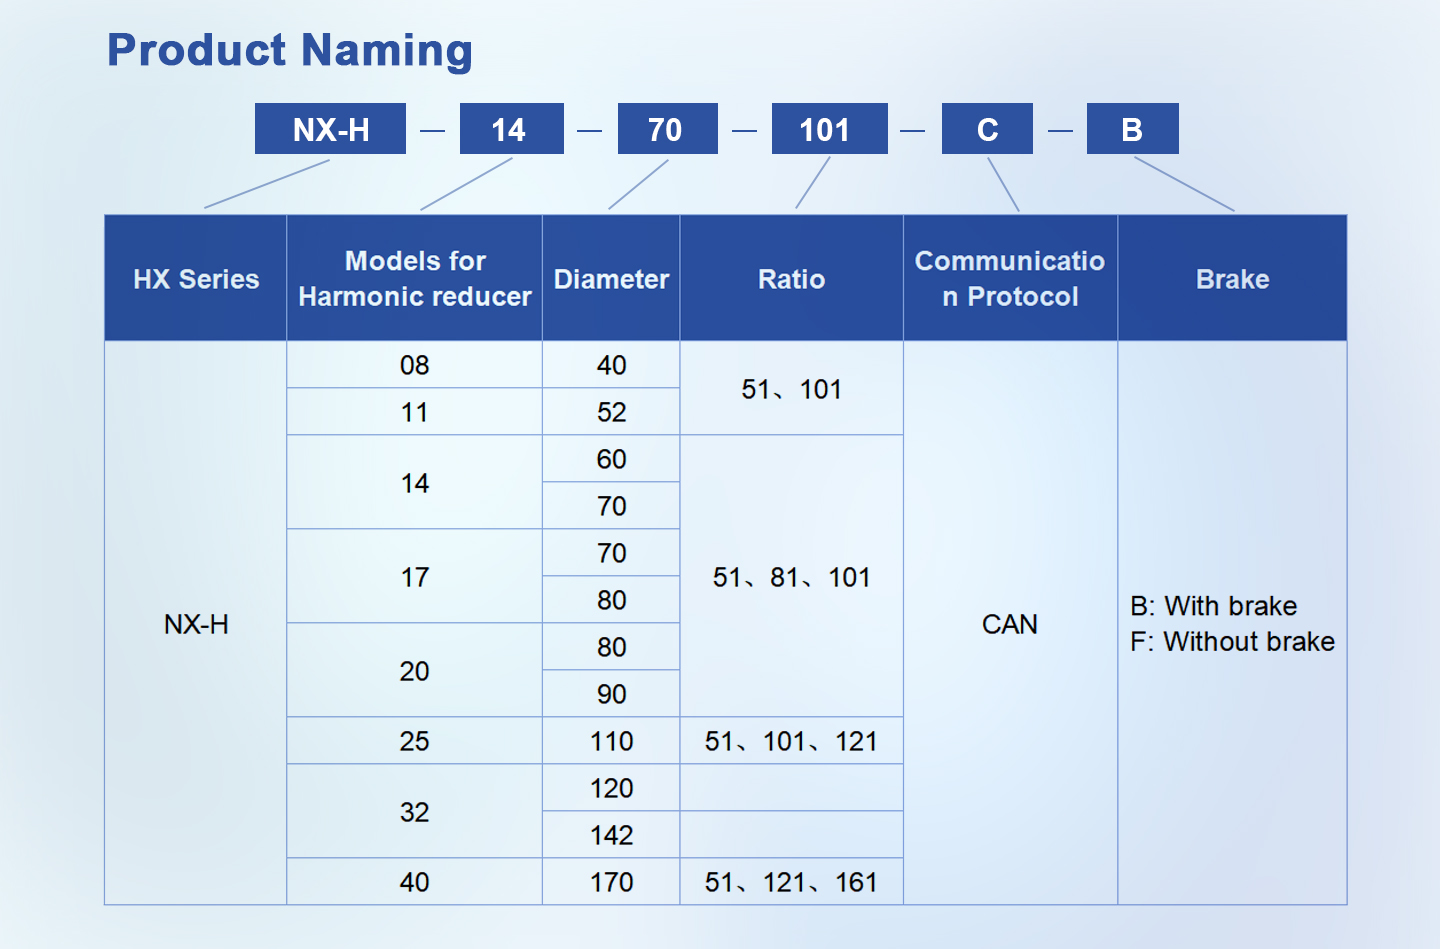
Product Naming
| Model | Reduction ratio |
Start-stop peak torque (N·m) |
Max. allowable average load torque (N·m) |
Rated torque (N·m) |
Rated speed (rpm) |
Outer diameter (mm) |
Length (mm) |
Weight (kg) Without / with brake |
Through hole (mm) |
| HX-H-08-40 | 51 / 101 | 3.3 / 4.8 | 2.3 / 3.3 | 1.8 / 2.4 | 90 / 45 | 40 | 60 | 0.18 / 0.26 | 4.5 |
| HX-H-11-52 | 51 / 101 | 8.3 / 11 | 5.5 / 8.9 | 3.5 / 5 | 80 / 40 | 52 | 72.7 | 0.30 / 0.33 | 6 |
| HX-H-14-60 | 51 / 81 / 101 | 23 / 30 / 36 | 9 / 14 / 14 | 7 / 10 / 10 | 58 / 37 / 30 | 60 | 85.2 | 0.45 / 0.58 | 13 |
| HX-H-14-70 | 51 / 81 / 101 | 23 / 30 / 36 | 9 / 14 / 14 | 7 / 10 / 10 | 58 / 37 / 30 | 70 | 82.2 | 0.63 / 0.76 | 10.5 |
| HX-H-17-70 | 51 / 81 / 101 | 44 / 56 / 70 | 34 / 35 / 51 | 21 / 29 / 31 | 58 / 37 / 30 | 70 | 82.7 | 0.74 / 0.86 | 18 |
| HX-H-17-80 | 51 / 81 / 101 | 44 / 56 / 70 | 34 / 35 / 51 | 21 / 29 / 31 | 58 / 37 / 30 | 80 | 83.2 | 1.00 / 1.18 | 12 |
| HX-H-20-80 | 51 / 81 / 101 | 73 / 96 / 107 | 44 / 61 / 64 | 33 / 44 / 52 | 58 / 37 / 30 | 80 | 88.2 | 1.00 / 1.20 | 18 |
| HX-H-20-90 | 51 / 81 / 101 | 73 / 96 / 107 | 44 / 61 / 64 | 33 / 44 / 52 | 58 / 37 / 30 | 90 | 88.2 | 1.30 / 1.50 | 13 |
| HX-H-25-110 | 51 / 101 / 121 | 127 / 204 / 217 | 72 / 140 / 140 | 51 / 87 / 87 | 58 / 30 / 28 | 110 | 94.3 | 2.00 / 2.20 | 25 |
| HX-H-32-120 | 51 / 101 / 121 | 253 / 390 / 413 | 126 / 253 / 253 | 89 / 160 / 160 | 58 / 30 / 28 | 120 | 116.6 | 3.50 / 4.00 | 35 |
| HX-H-32-142 | 51 / 101 / 121 | 281 / 433 / 459 | 140 / 281 / 281 | 99 / 178 / 178 | 58 / 30 / 28 | 142 | 116.6 | 3.80 / 4.30 | 32 |
| HX-H-40-170 | 51 / 121 / 161 | 523 / 802 / 841 | 255 / 586 / 586 | 169 / 382 / 382 | 49 / 20 / 15 | 170 | 139.5 | 6.85 / 7.60 | 33 |
The harmonic reducer uses an enhanced double-arc tooth profile developed for robotic applications. The design balances load capacity, fatigue life, and transmission efficiency while helping control temperature rise.
Multiple reduction ratios provide flexibility when selecting actuators for different joint.
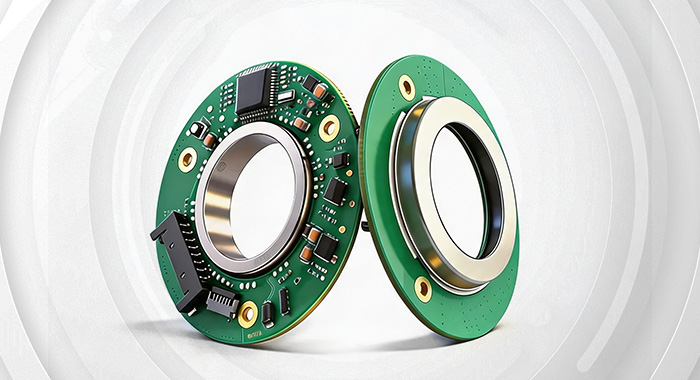
Dual encoders are standard across the series. Selected models use iC-Haus encoder technology with an off-axis arrangement that accommodates a central through-hole.
The selection catalogue specifies 17/19-bit resolution for the two smallest models and 19-bit resolution for the remaining models.
The servo drive combines three-shunt current sensing with sampling-window optimization to improve current measurement and reduce noise.
CORDIC hardware acceleration supports fast mathematical calculations, enabling control-loop frequencies above 20 kHz for responsive motor control.
The isolated CAN interface separates communication ground paths to reduce the effects of ground loops and potential differences.
This design helps improve communication stability in robotic systems where motor power wiring and signal cables share limited installation space.
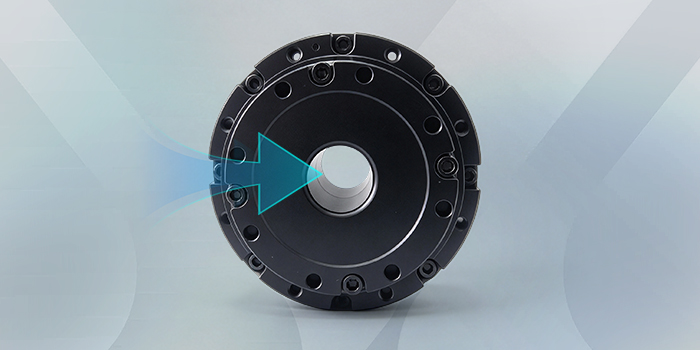
Through-hole diameters range from 4.5 to 35 mm, depending on the model.
The hollow structure allows cables to pass through the joint, helping reduce exposed wiring and simplify routing in multi-axis robotic assemblies.
An optional permanent magnet brake provides holding capability when power is removed.
Brake selection should match the joint’s holding torque and operating requirements, particularly for gravity-loaded axes.
Application
 Humanoid robot
Robotic dog
 Robotic arm
Exoskeleton robot
| Model | HX-H-08-40 | HX-H-11-52 | HX-H-14-60 | HX-H-14-70 | HX-H-17-70 | HX-H-17-80 |
| Outer diameter (mm) | 40 | 52 | 60 | 70 | 70 | 80 |
| Reduction ratio | 51 / 101 | 51 / 101 | 51 / 81 / 101 | 51 / 81 / 101 | 51 / 81 / 101 | 51 / 81 / 101 |
| Start stop peak torque (N·m) | 3.3 / 4.8 | 8.3 / 11 | 23 / 30 / 36 | 23 / 30 / 36 | 44 / 56 / 70 | 44 / 56 / 70 |
| Max allowable average load torque (N·m) | 2.3 / 3.3 | 5.5 / 8.9 | 9 / 14 / 14 | 9 / 14 / 14 | 34 / 35 / 51 | 34 / 35 / 51 |
| Rated torque (N·m) | 1.8 / 2.4 | 3.5 / 5 | 7 / 10 / 10 | 7 / 10 / 10 | 21 / 29 / 31 | 21 / 29 / 31 |
| Peak output speed (rpm) | 118 / 59 | 118 / 59 | 85 / 55 / 45 | 85 / 55 / 45 | 85 / 55 / 45 | 85 / 55 / 45 |
| Rated speed (rpm) | 90 / 45 | 80 / 40 | 58 / 37 / 30 | 58 / 37 / 30 | 58 / 37 / 30 | 58 / 37 / 30 |
| Motor power (W) | 36 | 90 | 85 | 85 | 150 | 150 |
| Rated current (A) | 1 | 2 | 2.5 | 2.5 | 5 | 5 |
| Encoder resolution (bit) | 17/19 | 17/19 | 19 | 19 | 19 | 19 |
| Backlash (arcsec) | 40 / 40 | 40 / 30 | 20 / 20 / 10 | 20 / 20 / 10 | 20 / 20 / 10 | 20 / 20 / 10 |
| Length (mm) | 60 ± 0.5 | 72.7 ± 0.5 | 85.2 ± 0.5 | 82.2 ± 0.5 | 82.7 ± 0.5 | 83.2 ± 0.5 |
| Through hole diameter (mm) | 4.5 | 6 | 13 | 10.5 | 18 | 12 |
| Weight without brake (kg) | 0.18 | 0.30 | 0.45 | 0.63 | 0.74 | 1.00 |
| Inertia without brake (g·cm²) | 26.2 | 69.6 | 135.1 | 133 | 376.5 | 361.3 |
| Weight with brake (kg) | 0.26 | 0.33 | 0.58 | 0.76 | 0.86 | 1.18 |
| Inertia with brake (g·cm²) | 35.8 | 87.8 | 195.6 | 185 | 481.3 | 465 |
| Supply voltage (V DC) | 24–48 | 24–48 | 24–48 | 24–48 | 24–48 | 24–48 |
| Model | HX-H-20-80 | HX-H-20-90 | HX-H-25-110 | HX-H-32-120 | HX-H-32-142 | HX-H-40-170 |
| Outer diameter (mm) | 80 | 90 | 110 | 120 | 142 | 170 |
| Reduction ratio | 51 / 81 / 101 | 51 / 81 / 101 | 51 / 101* / 121 | 51 / 101 / 121 | 51 / 101 / 121 | 51 / 121 / 161 |
| Start stop peak torque (N·m) | 73 / 96 / 107 | 73 / 96 / 107 | 127 / 204 / 217 | 253 / 390 / 413 | 281 / 433 / 459 | 523 / 802 / 841 |
| Max allowable average load torque (N·m) | 44 / 61 / 64 | 44 / 61 / 64 | 72 / 140 / 140 | 126 / 253 / 253 | 140 / 281 / 281 | 255 / 586 / 586 |
| Rated torque (N·m) | 33 / 44 / 52 | 33 / 44 / 52 | 51 / 87 / 87 | 89 / 160 / 160 | 99 / 178 / 178 | 169 / 382 / 382 |
| Peak output speed (rpm) | 85 / 55 / 45 | 85 / 55 / 45 | 85 / 45 / 37 | 78 / 40 / 33 | 78 / 40 / 33 | 63 / 26 / 20 |
| Rated speed (rpm) | 58 / 37 / 30 | 58 / 37 / 30 | 58 / 30 / 28 | 58 / 30 / 28 | 58 / 30 / 28 | 49 / 20 / 15 |
| Motor power (W) | 300 | 300 | 750 | 1000 | 1000 | 1500 |
| Rated current (A) | 6.3 | 6.3 | 10.5 | 18.5 | 18.5 | 25 |
| Encoder resolution (bit) | 19 | 19 | 19 | 19 | 19 | 19 |
| Backlash (arcsec) | 20 / 20 / 10 | 20 / 20 / 10 | 20 / 10 / 10 | 20 / 10 / 10 | 20 / 10 / 10 | 20 / 20 / 10 |
| Length (mm) | 88.2 ± 0.5 | 88.2 ± 0.5 | 94.3 ± 0.5 | 116.6 ± 0.5 | 116.6 ± 0.5 | 139.5 ± 0.5 |
| Through hole diameter (mm) | 18 | 13 | 25 | 35 | 32 | 33 |
| Weight without brake (kg) | 1.00 | 1.30 | 2.00 | 3.50 | 3.80 | 6.85 |
| Inertia without brake (g·cm²) | 577.4 | 551.5* | 1392.6 | 3560 | 3861.2 | 8107.3 |
| Weight with brake (kg) | 1.20 | 1.50 | 2.20 | 4.00 | 4.30 | 7.60 |
| Inertia with brake (g·cm²) | 735.5 | 706 | 1565.4 | 4500 | 5635.6 | 10251.2 |
| Supply voltage (V DC) | 24–48 | 24–48 | 24–48 | 24–48 | 24–48 | 24–48 |
| Communication protocol | CAN | CAN | CAN | CAN | CAN | CAN |
| Dual encoders | Standard | Standard | Standard | Standard | Standard | Standard |
| Brake | Optional | Optional | Optional | Optional | Optional | Optional |