
Home > Case
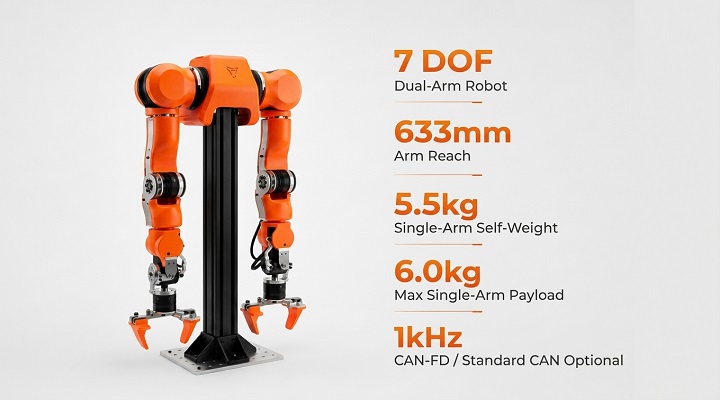
Open-TArm 1.0 is a fully open-source 7-DOF humanoid robotic arm platform, designed for Physical AI research, robotics education, and real-world applications.
It features a symmetrical dual-arm design with human-like proportions, suitable for a 160–165 cm
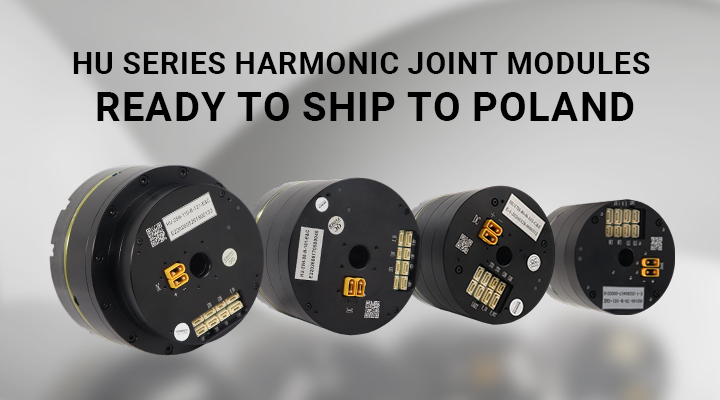
Another batch of our HU Series harmonic joint modules is ready to ship to Poland for a 6-axis, 5 kg payload robot.
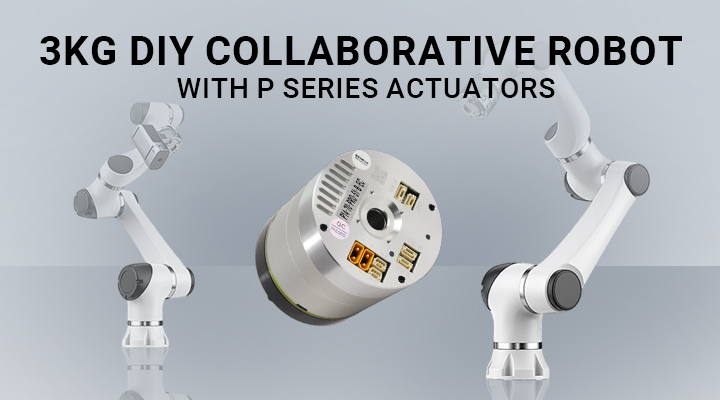
What happens to the voltage when a small collaborative robot runs at different speeds?
We built a 3kg DIY collaborative robot using our P Series harmonic joint modules and tested the instantaneous voltage during different motion speeds.
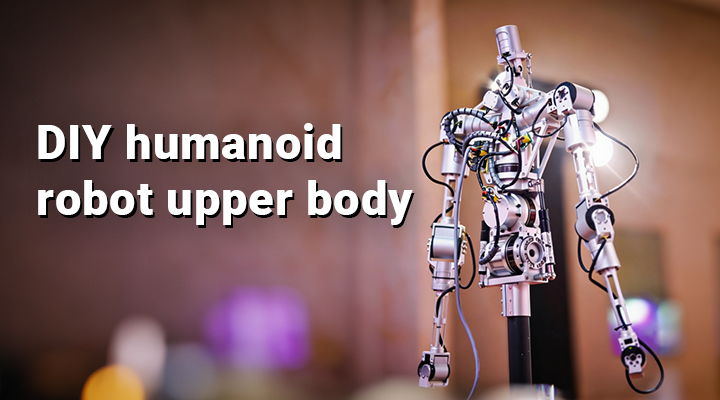
Designed for beginners, students, and robotics researchers, this humanoid robot upper body combines planetary joint modules and harmonic joint modules to create a flexible and realistic robotic structure.
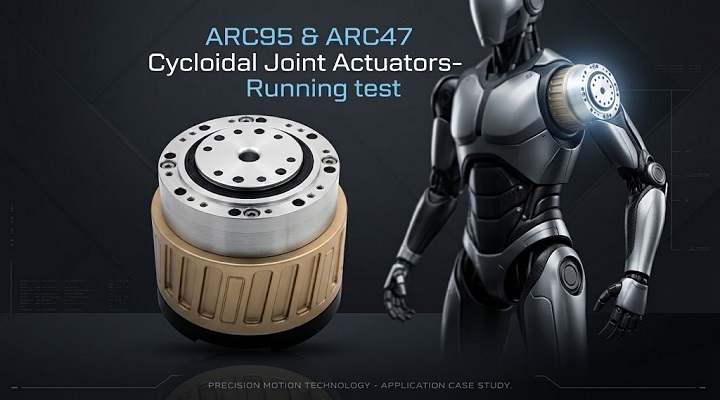
The ARC95 and ARC47 cycloidal joint modules are now running with an upper-level controller, demonstrating their excellent motion performance and stability.
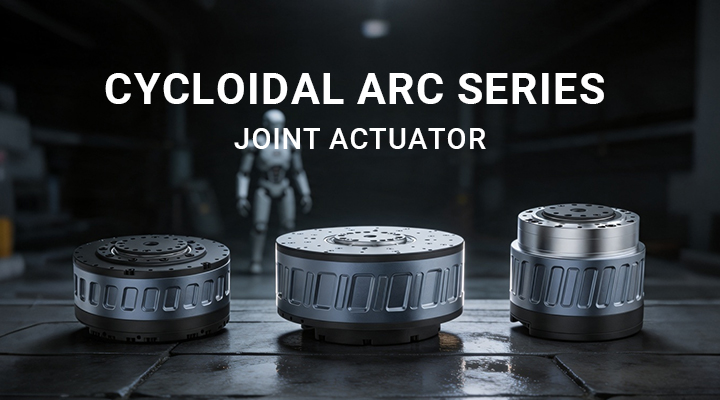
Our customer needed a compact joint solution with high torque, high rigidity, and excellent shock resistance for a humanoid robot.
We provided a cycloidal joint module that integrates the motor, reducer, encoder, and control system into one compact unit.
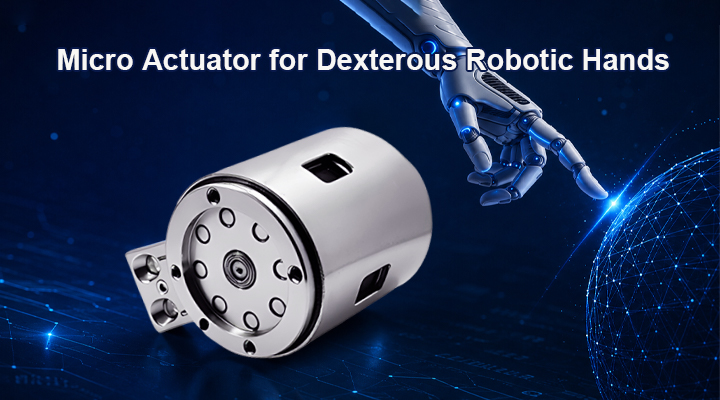
Enabling Next-Generation Robotic Hands with Ultra-Compact, High-Torque Joint Actuation. Designed for high-precision dexterous robotic hand joints, this 16mm–30mm miniature actuator integrates an advanced axial flux motor, high-density HDI interconnect boa
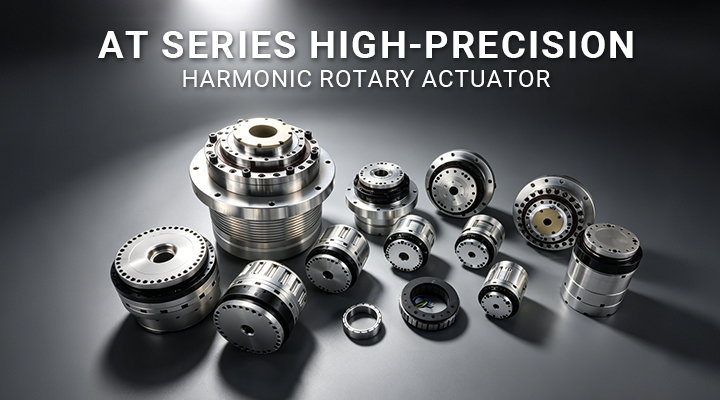
The AT Series high-precision harmonic rotary actuator is specially designed for the A/C axes of 5-axis grinding robots, delivering exceptional positioning accuracy and outstanding dynamic performance.
With a positioning accuracy of ±30 arcsec and axial/r
