
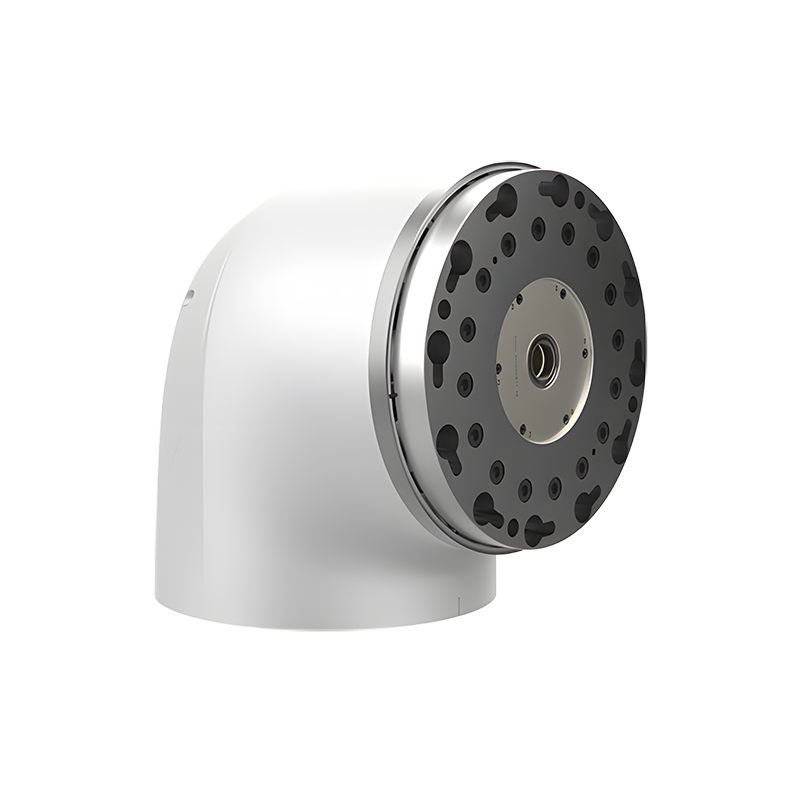
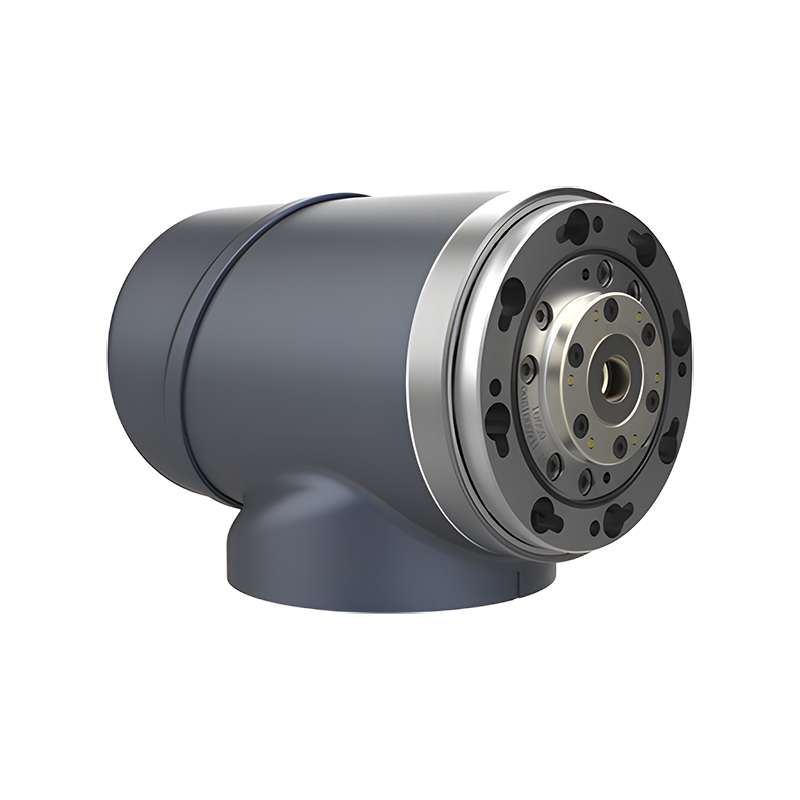
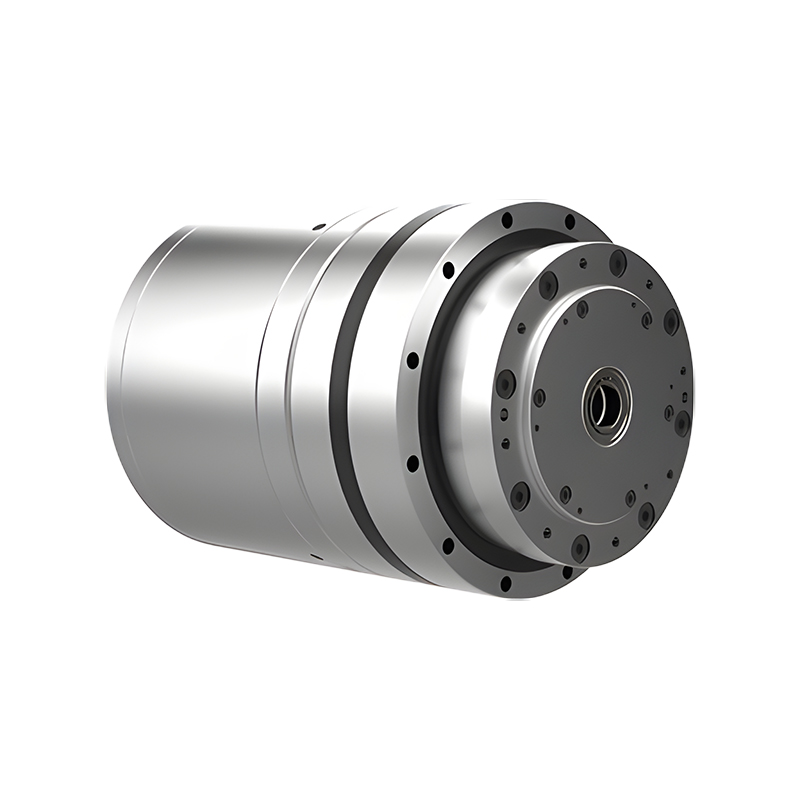
TH actuators have three types of housings: L-Type, T-type and I-type
Supporting different structures, appearances, colors, etc.
Compatible with various scenarios: industry, medical, service, etc.
Models: TH14, TH17, TH20, TH25, TH32, TH40
Through-hole diameters: 8/11/12/16mm
Rated torques: 10Nm to 382Nm.
Communication protocol: EtherCAT,CiA402
Rated power: 159-1257W
Rated Voltage: 48V
Brake: Electromagnetic friction type
All-in-One Integration of Harmonic Reducer, Motor, Dual Encoders, Brake, Drive, and Torque Sensor
TH modular joint actuators integrates the harmonic reducer, motor, dual encoders, brake, drive, and torque sensor into a compact all-in-one solution. Designed for collaborative, bionic, medical, and humanoid robots.
| Model | TH14 | TH17 | TH20 | TH25 | TH32 | TH40 |
Rated torque (Nm) |
10 | 31 | 52 | 87 | 178 | 382 |
| Rated speed (rpm) | 49.5 | 34.6 | 34.6 | 28.9 | 24.7 | 18.6 |
| Rated power (W) | 159 | 183 | 366 | 732 | 1000 | 1257 |
| Rated voltage (VDC) | 48 | 48 | 48 | 48 | 48 | 48 |
| Rated current (A) | 4.4 | 5 | 9.7 | 16 | 27 | 27 |
| Communication protocol | EtherCAT,CiA402 | |||||
| Through hole diameter (mm) | 8 | 11 | 8 | 12 | 16 | 16 |
| Gear ratio | 101 | 101 | 101 | 121 | 121 | 161 |
| Encoder | Dual absolute magnetic encoder, output resolution 19Bits | |||||
| Brake | Electromagnetic friction type | |||||
| IP classification | IP54 | |||||
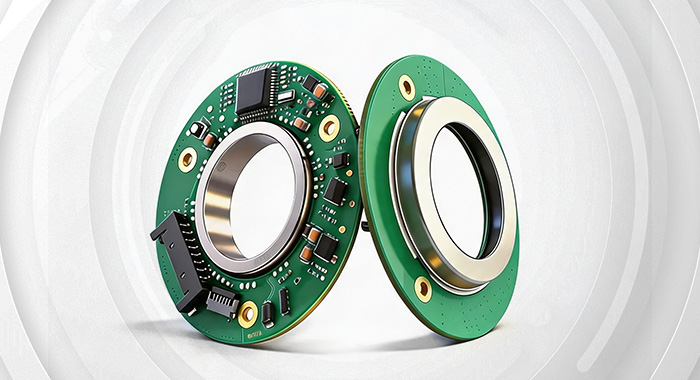
Low Inertia · Stable Torque · High Peak Torque · Fast Dynamic Response
Overcurrent, overvoltage, undervoltage, overtemperature, PWM dead-time, and PWM shoot-through protection, effectively reducing the risk of electrical and mechanical damage to the joint.
IP54
TH14I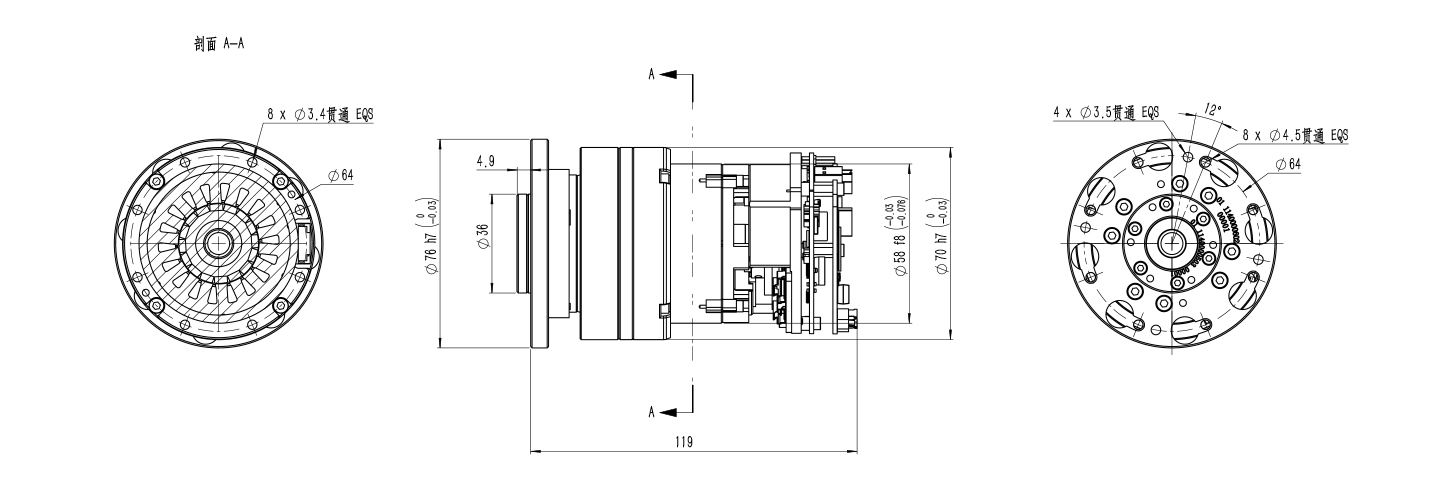
TH14L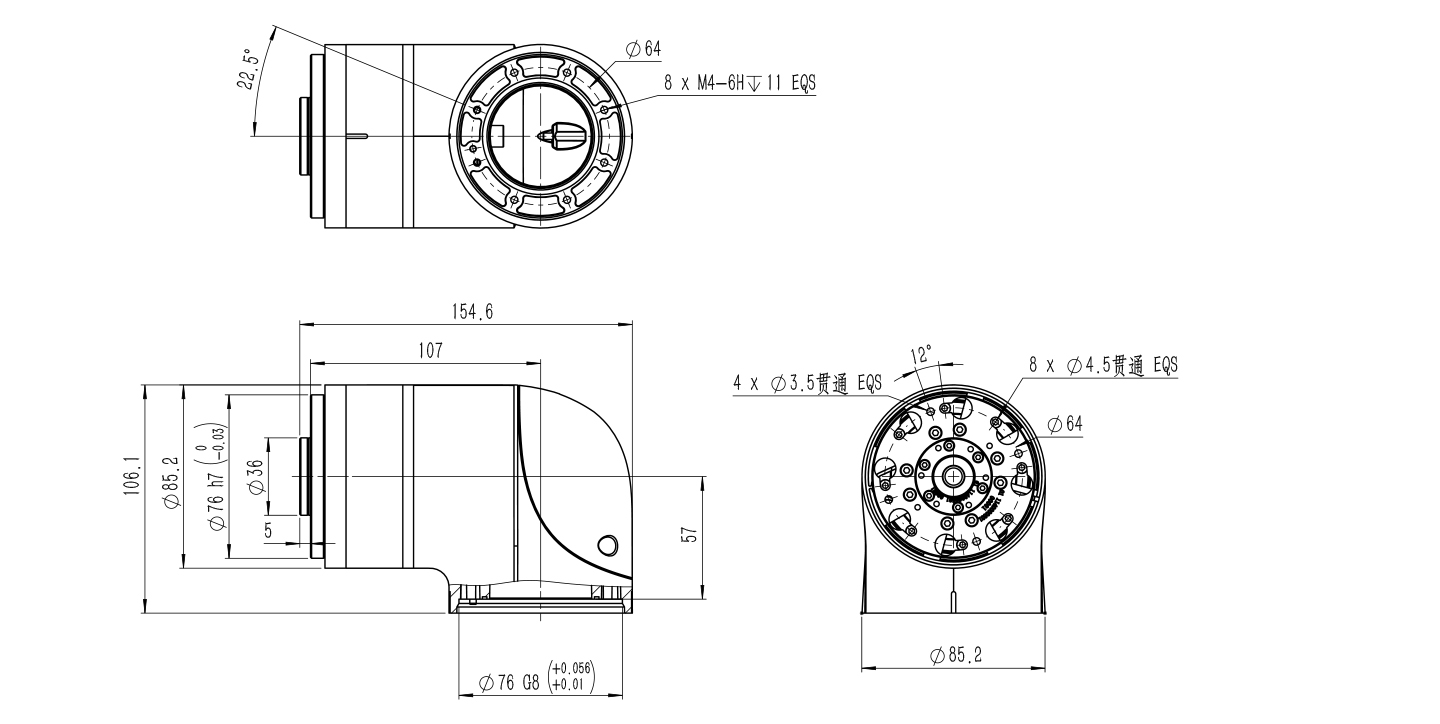
TH14T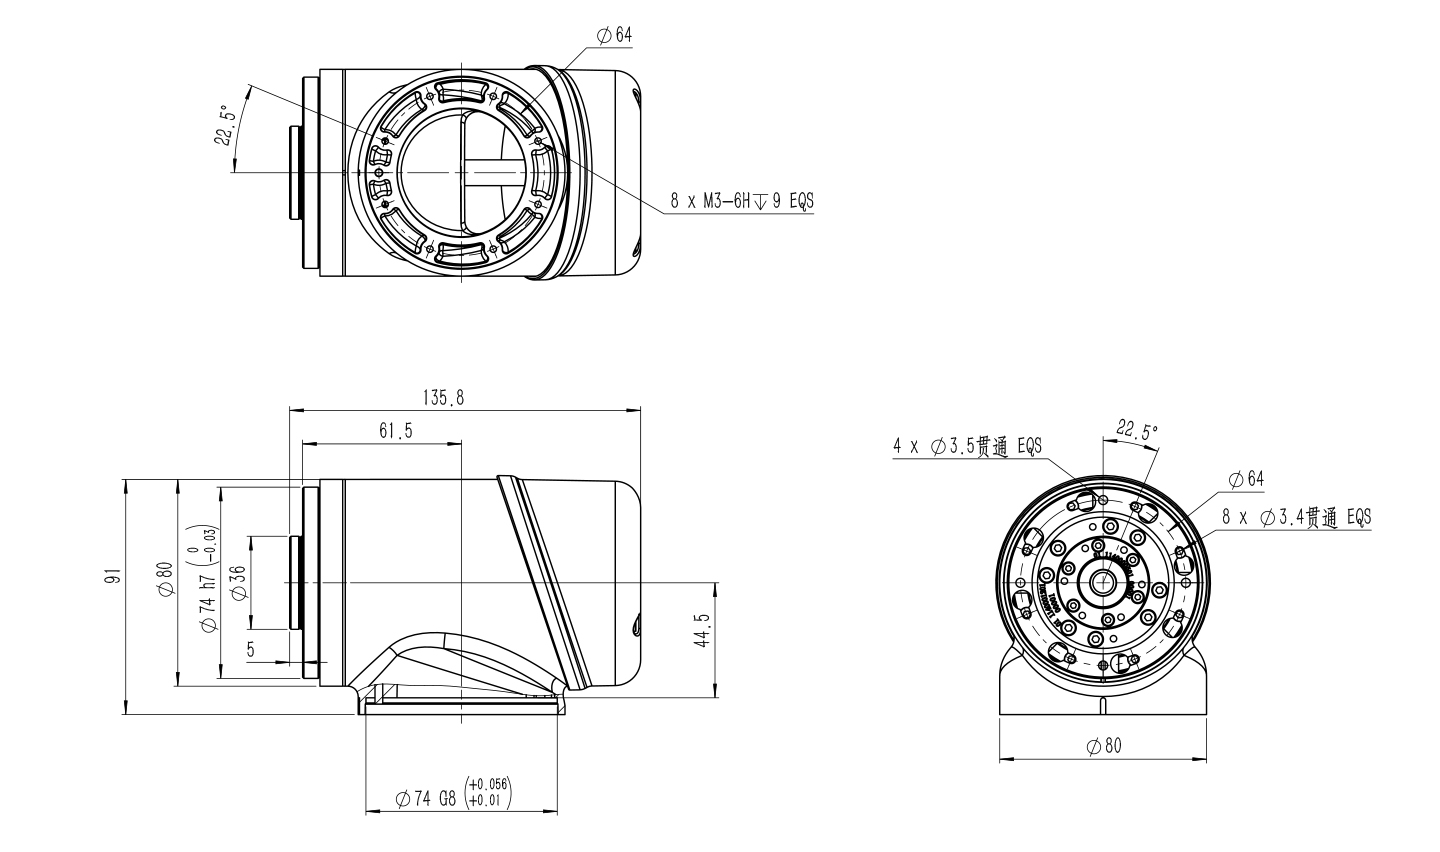
TH17I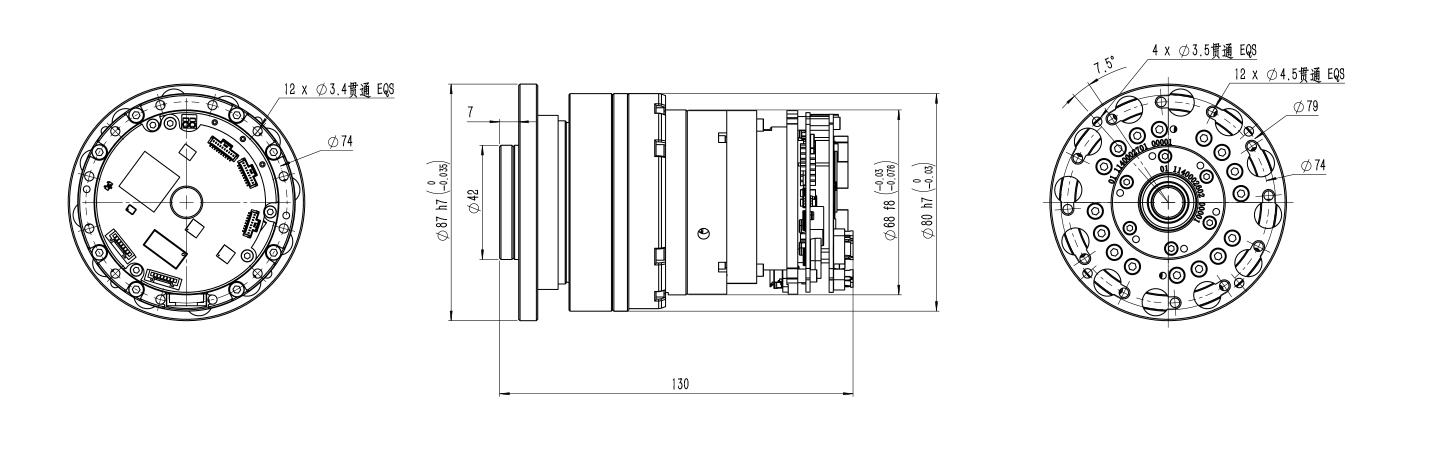
TH17L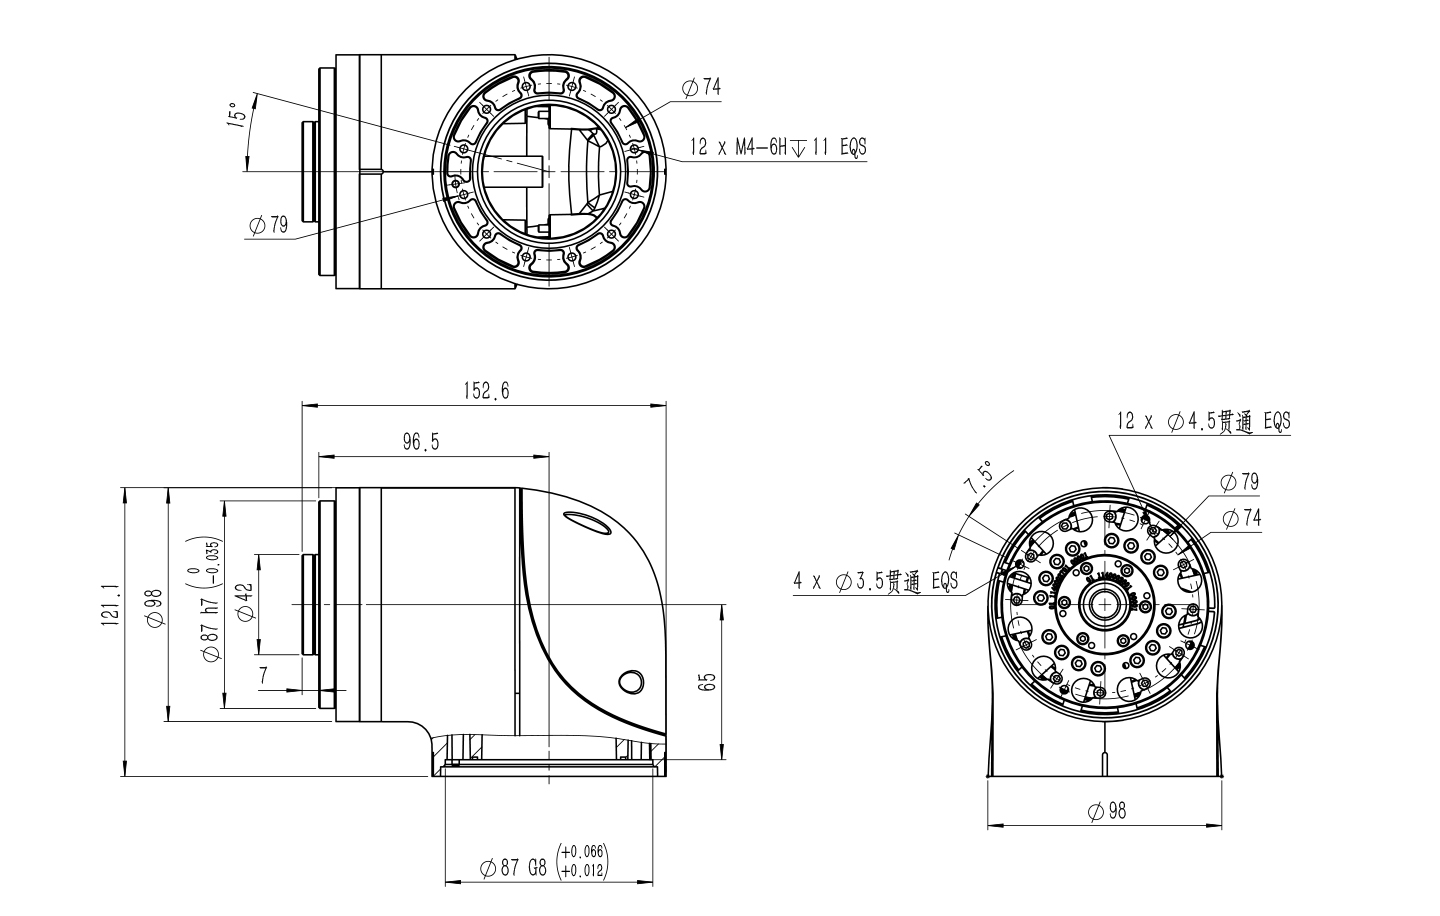
TH17T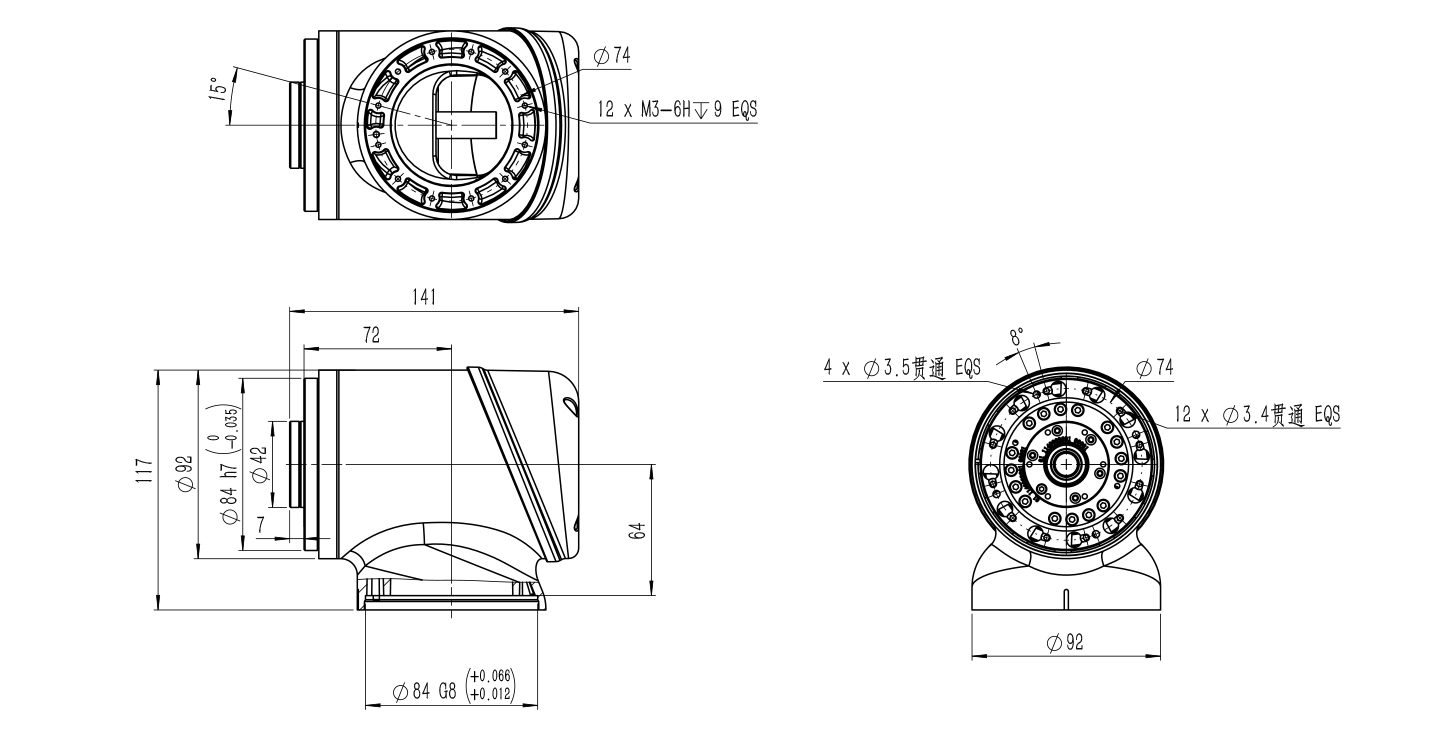
TH20I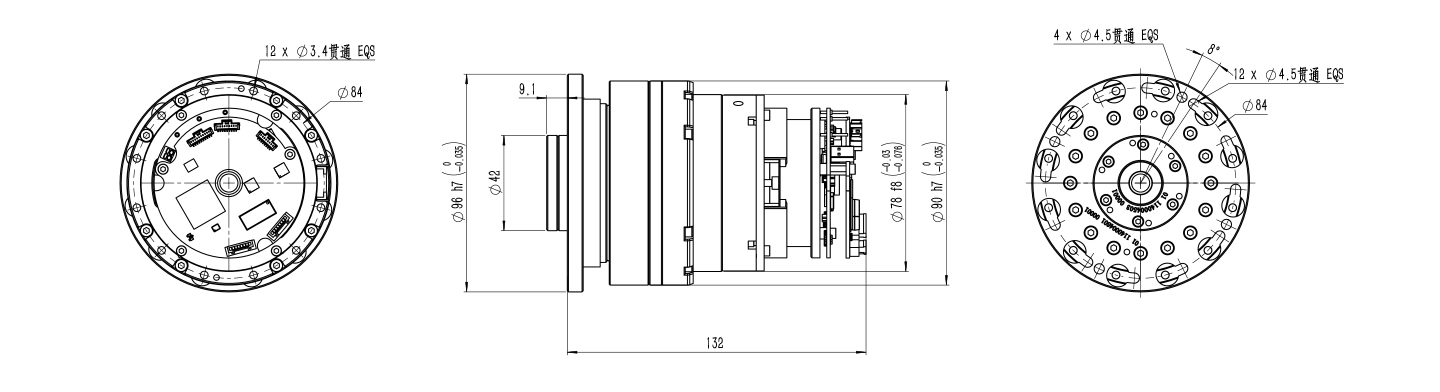
TH20L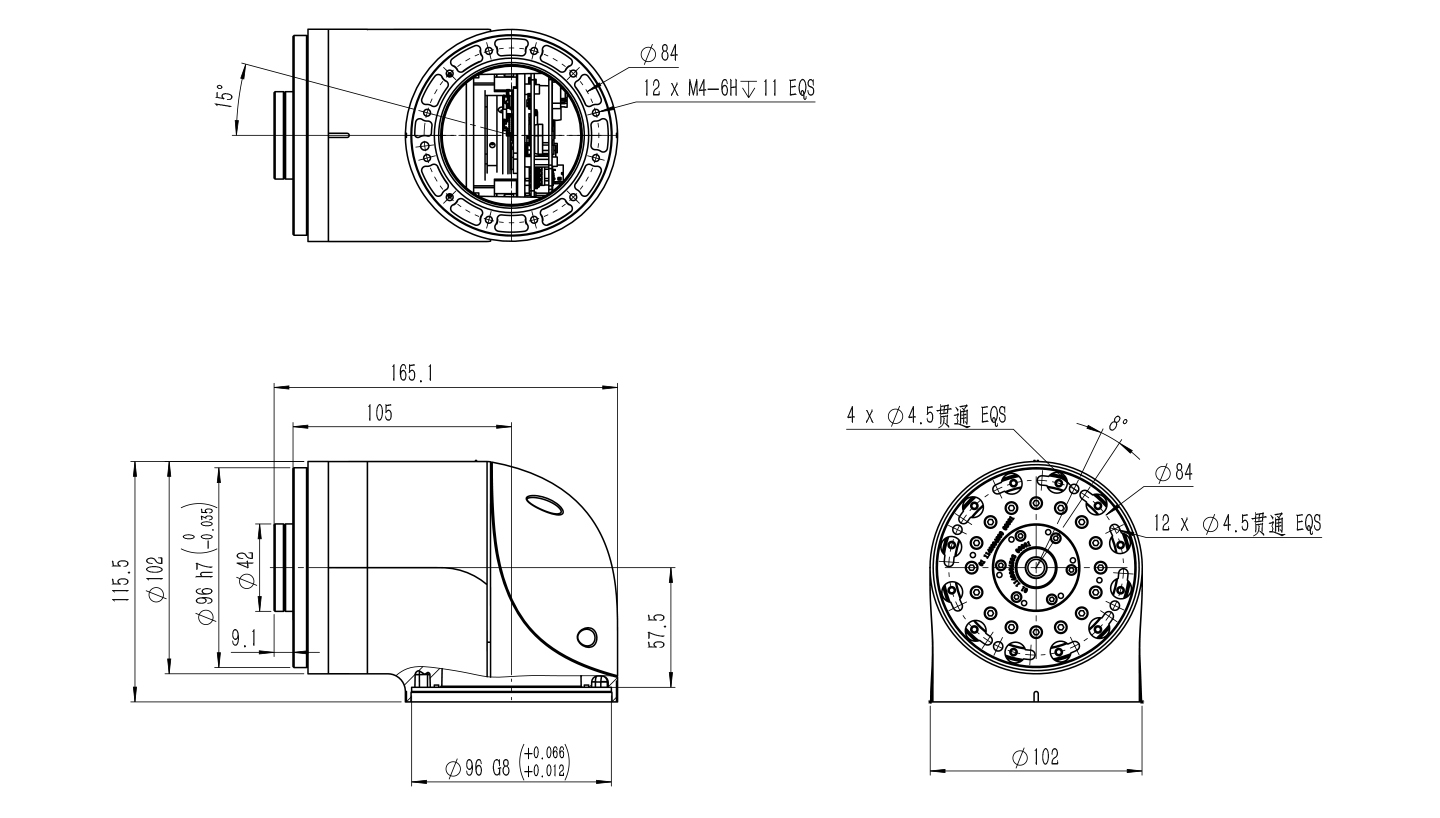
TH20T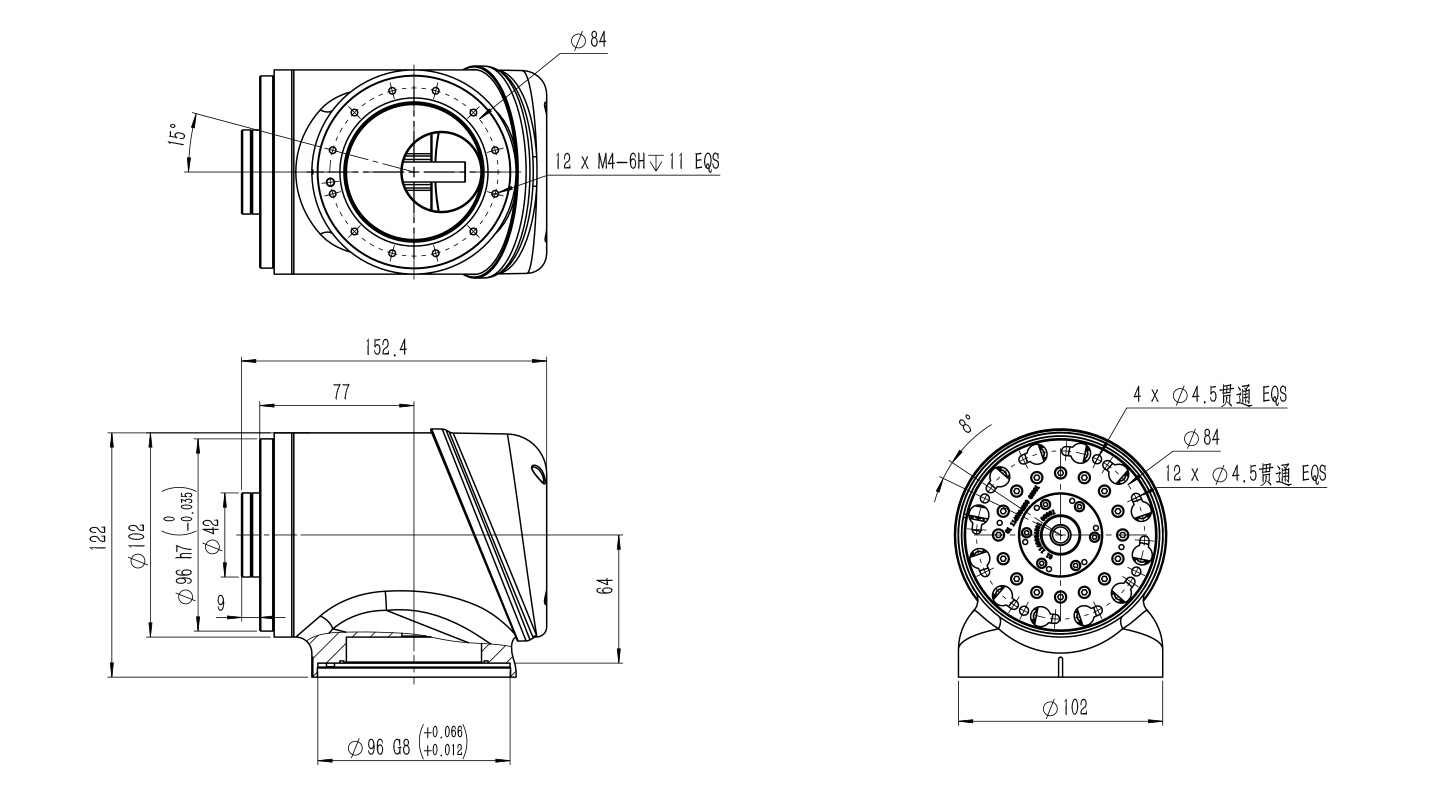
TH25I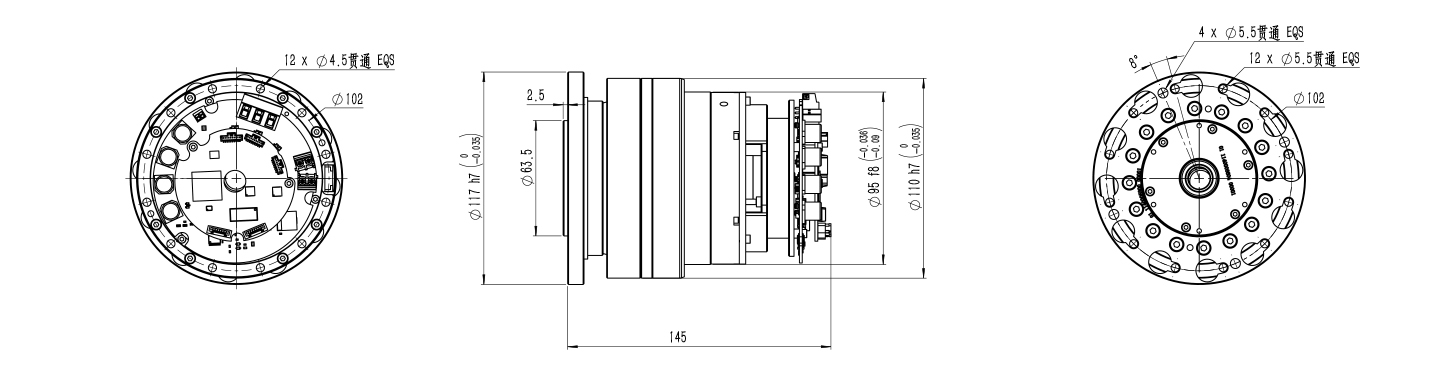
TH25L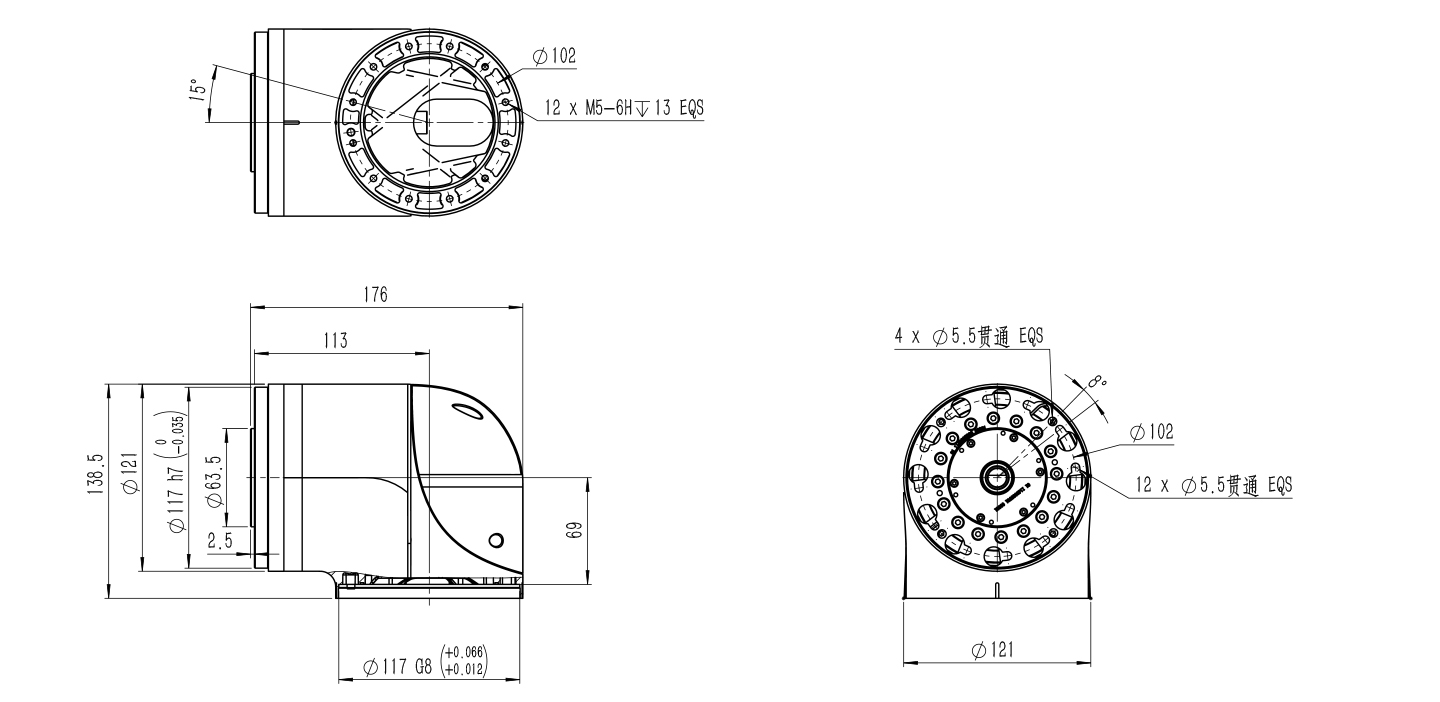
TH25T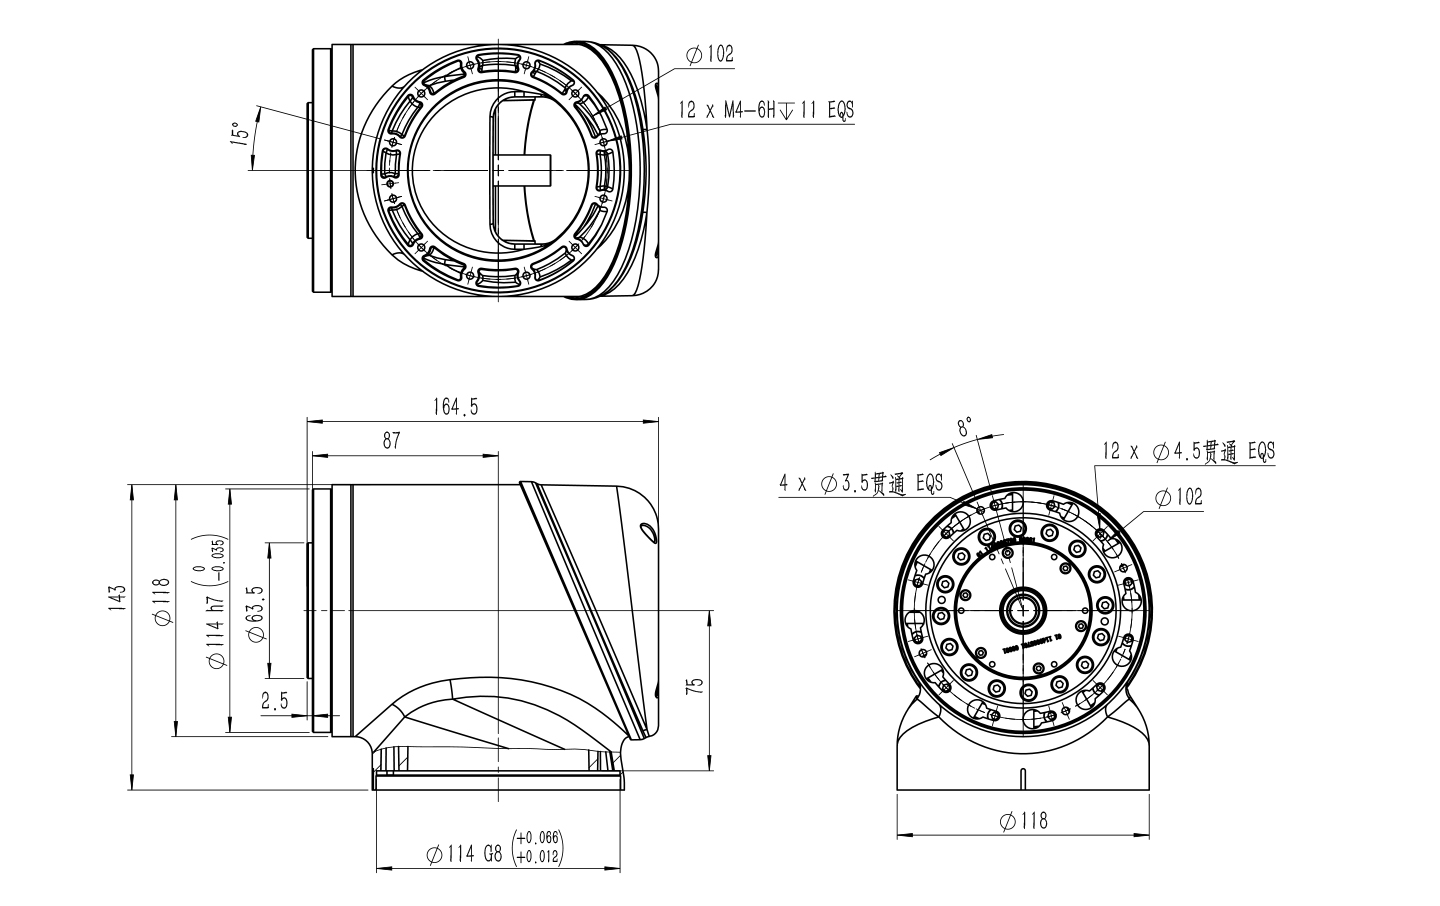
TH32I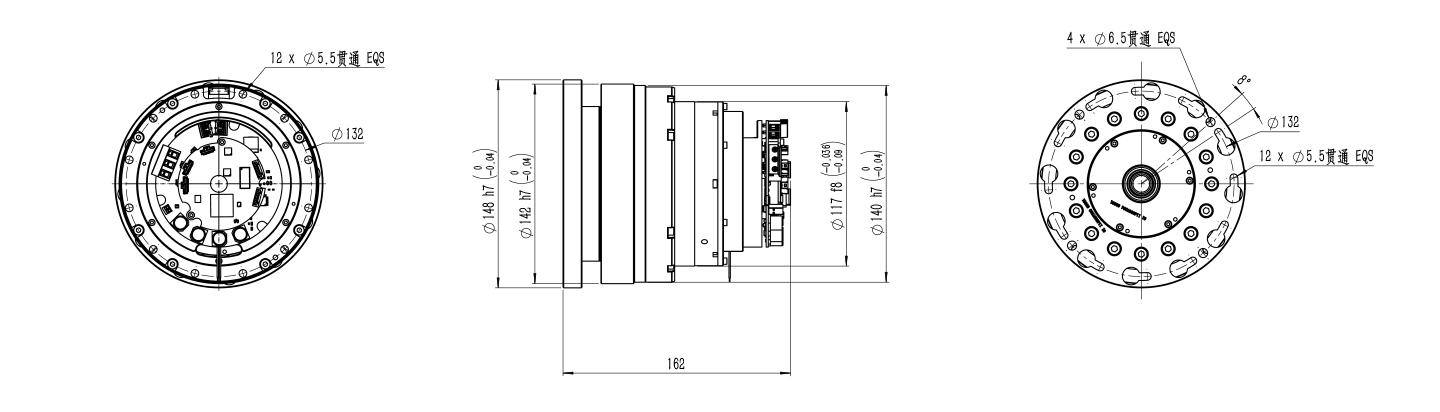
TH32L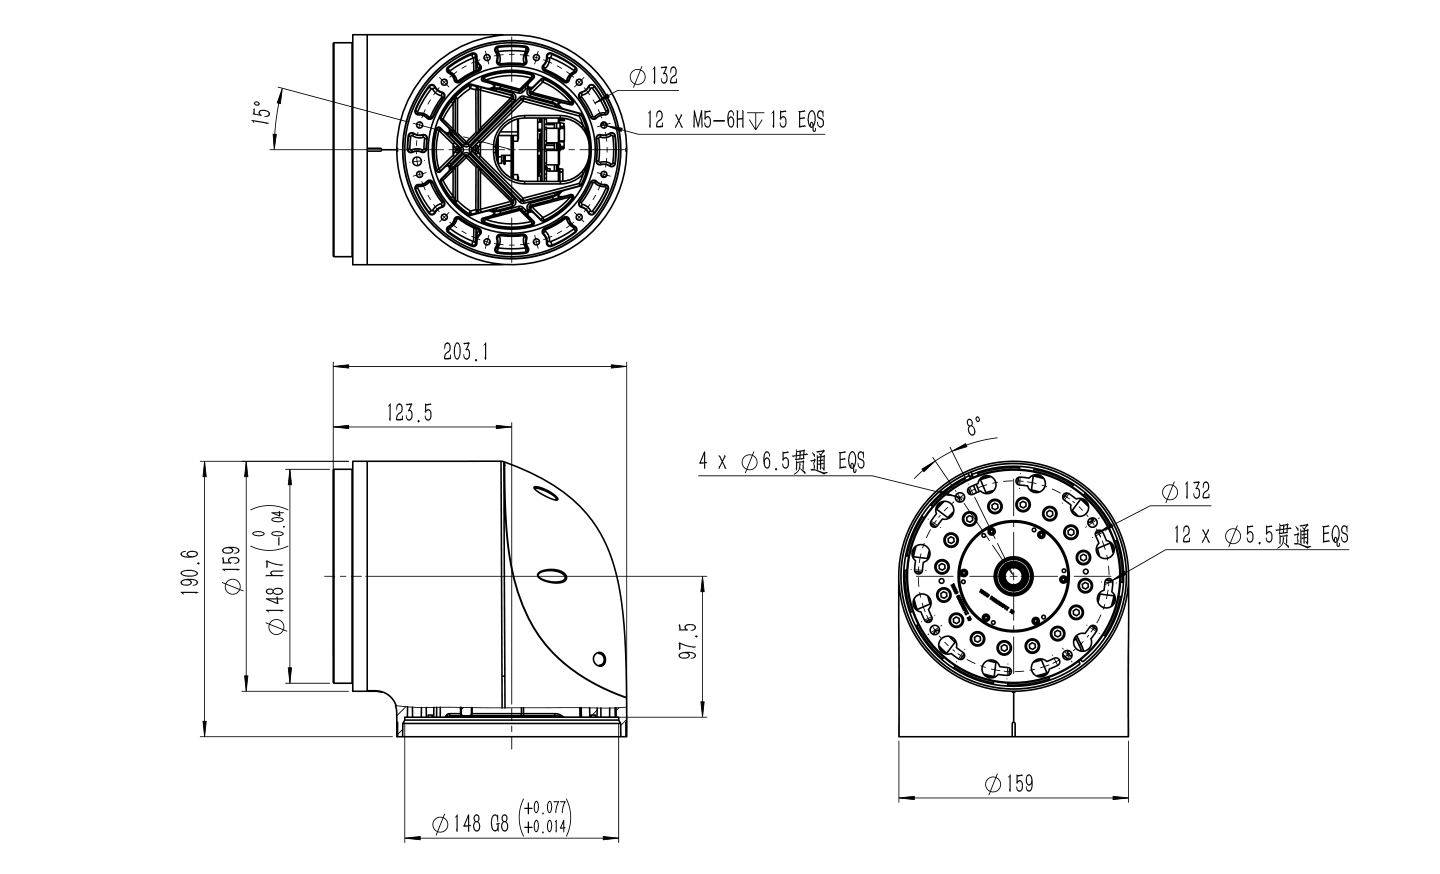
TH40I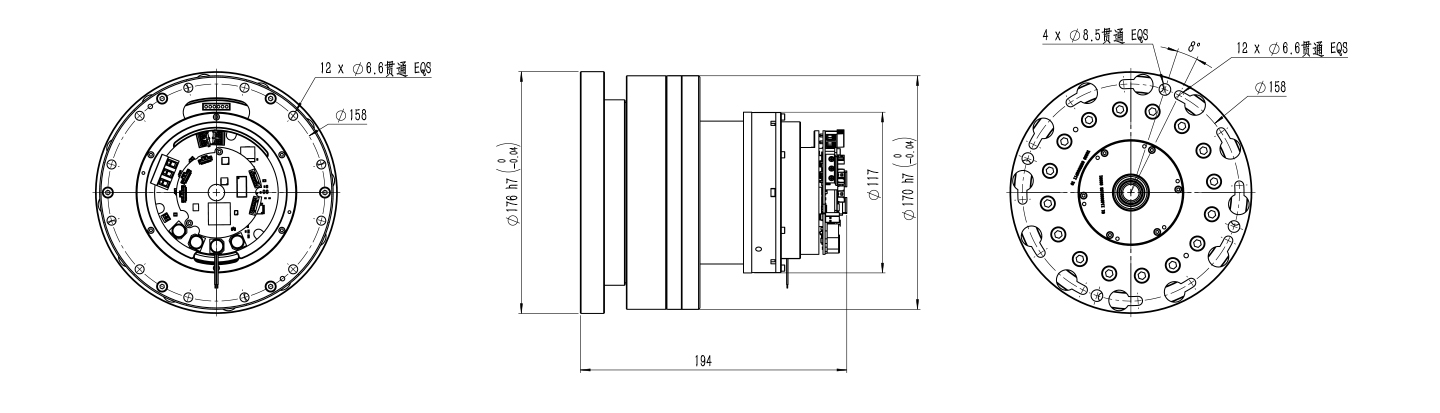
TH40L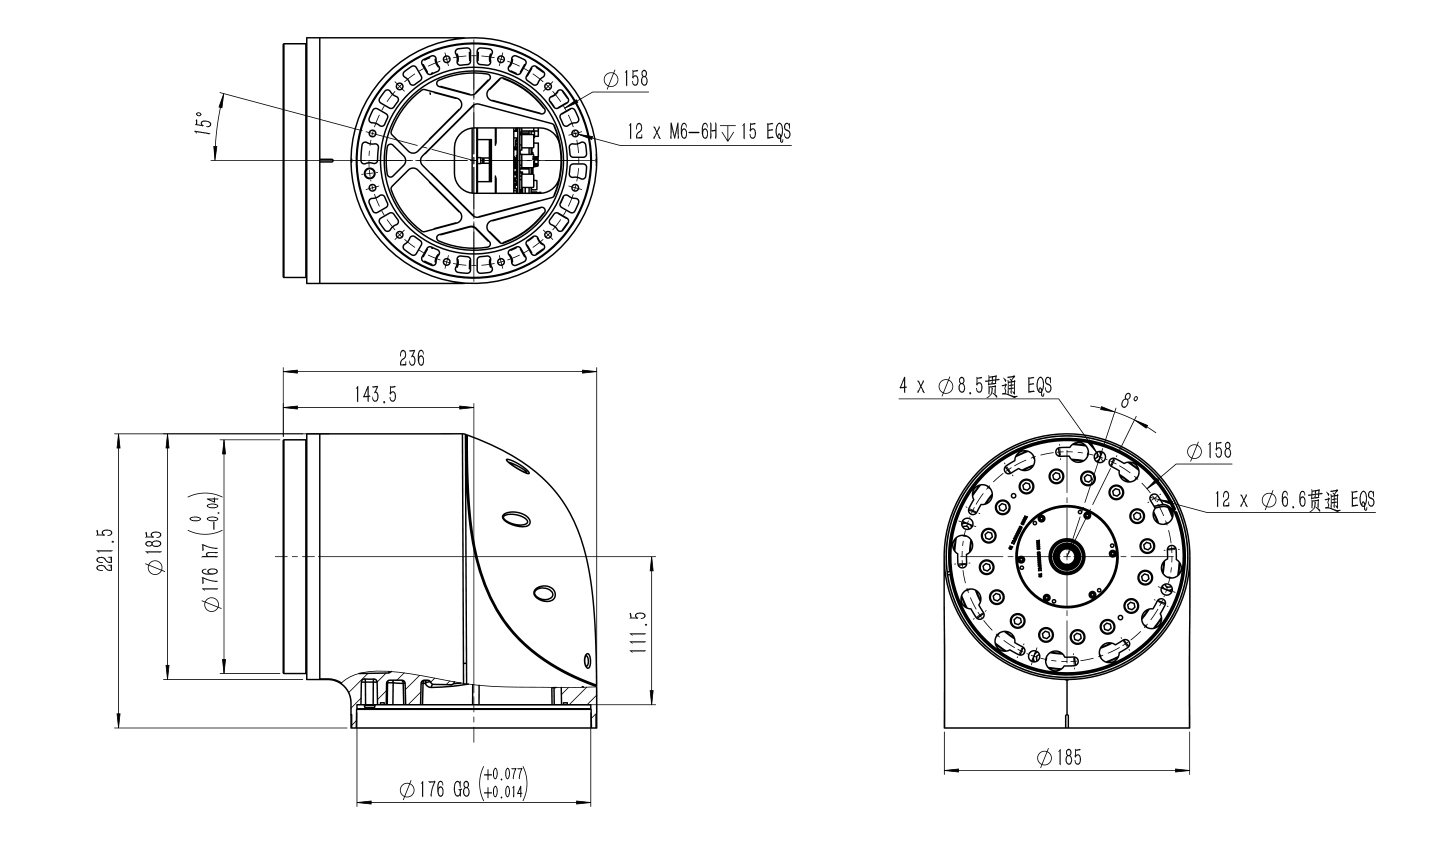
V. Product Application
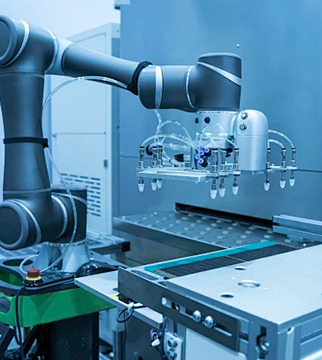 Medical Robot Arm
Precision Manufacturing
Research and Development
 Humanoid Robot
| Model | TH14 | TH17 | TH20 | TH25 | TH32 | TH40 | |
| Basic Performance | Rated torque (Nm) | 10 | 31 | 52 | 87 | 178 | 382 |
| Allowable max torque for start/stop (Nm) | 36 | 70 | 107 | 217 | 459 | 841 | |
| Allowable max instantaneous torque (Nm) | 70 | 143 | 191 | 395 | 892 | 1530 | |
| Max torque at average load (Nm) | 14 | 51 | 64 | 140 | 281 | 586 | |
| Rated speed (rpm) | 49.5 | 34.6 | 34.6 | 28.9 | 24.7 | 18.6 | |
| Max speed (rpm) | 56 | 44 | 39.8 | 30 | 31 | 18.6 | |
| Positioning accuracy (deg) | +/-0.01 | ||||||
| Electrical Performance | Rated power (W) | 159 | 183 | 366 | 732 | 1000 | 1257 |
| Rated voltage (VDC) | 48 | 48 | 48 | 48 | 48 | 48 | |
| Rated current (A) | 4.4 | 5 | 9.7 | 16 | 27 | 27 | |
| Peak current (A) | 13.6 | 15 | 29.1 | 48 | 89 | 72 | |
| Communication protocol | EtherCAT,CiA402 | ||||||
| Mechanical Performance | Through hole diameter (mm) | 8 | 11 | 8 | 12 | 16 | 16 |
| Gear ratio | 101 | 101 | 101 | 121 | 121 | 161 | |
| Encoder | Dual absolute magnetic encoder, output resolution 19Bits | ||||||
| Brake | Electromagnetic friction type | ||||||
| IP classification | IP54 | ||||||
| Weight (kg) | I-TYPE | 1.24 | 1.6 | 2.06 | 3.37 | 6.16 | 9.72 |
| L-TYPE | 1.77 | 2.35 | 2.79 | 4.48 | 8.67 | 13.55 | |
| T-TYPE | 1.62 | 2.22 | 2.97 | 4.36 | / | / | |
| Diameter (mm) | I-TYPE | 76 | 87 | 96 | 117 | 148 | 176 |
| L-TYPE | 85 | 98 | 102 | 121 | 159 | 185 | |
| T-TYPE | 80 | 92 | 102 | 118 | / | / | |
| Length (mm) | I-TYPE | 122 | 128 | 139 | 145.6 | 160 | 192 |
| L-TYPE | 154.6 | 152.6 | 165 | 176 | 203 | 236 | |
| T-TYPE | 136 | 141 | 152.4 | 164.5 | / | / | |
