LE Series Inverted Planetary Roller Screw – Linear-Type Electrically Driven Joint
LE Series Linear Electric-driven joints
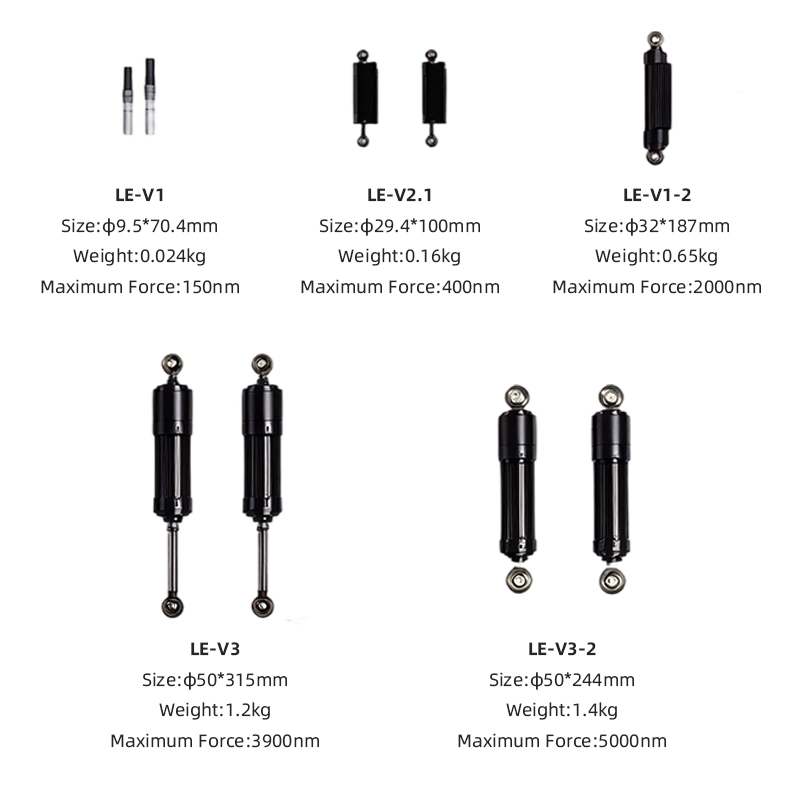
400-5000Nm Max Force
48DC±10% voltage
CANFD/ETHERCAT
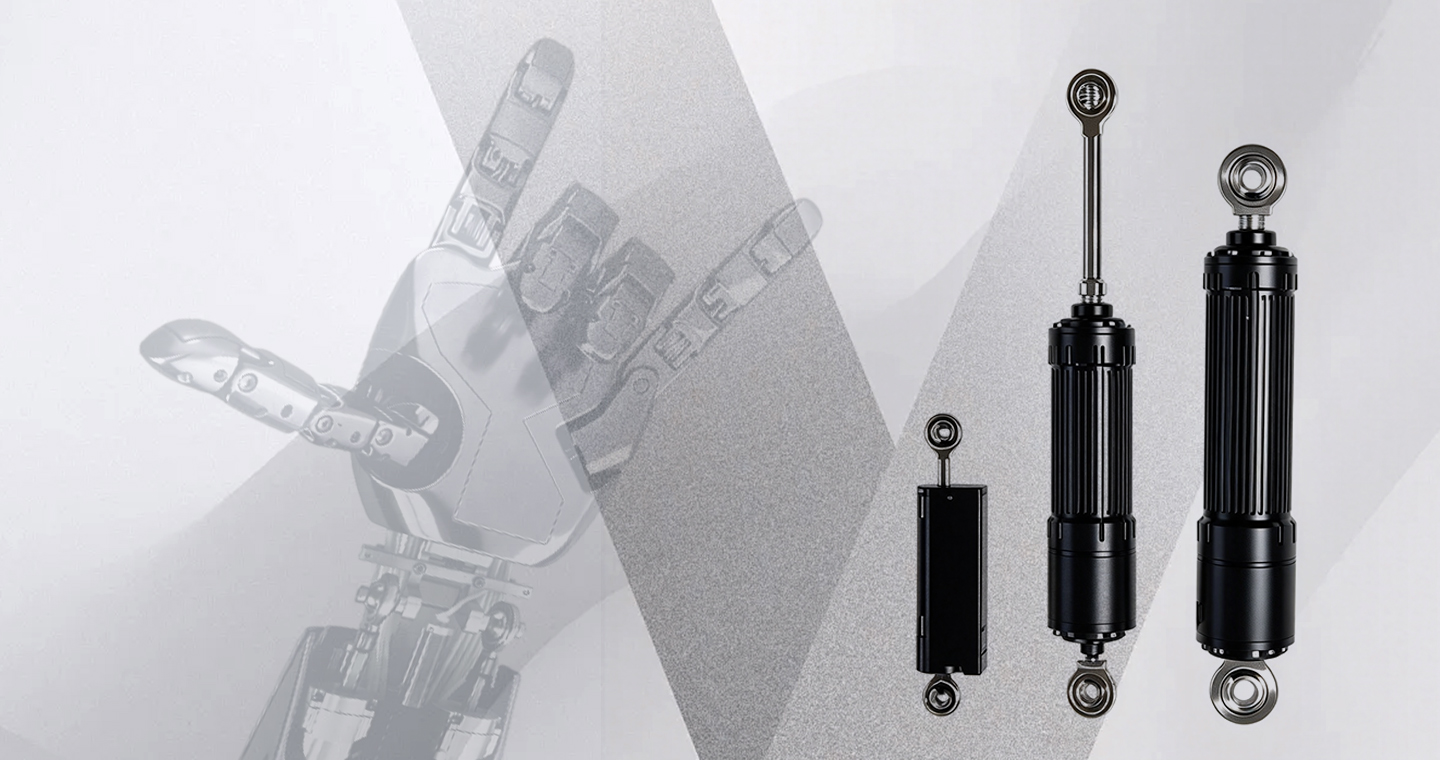
| NO. | Max. Force(Standard Product) | Max. speed(Standard Product) | Size(Standard Product) | Stroke(Standard Product) | Weight(Standard Product) | Brake(Standard Product) | Rated voltage(Standard Product) | Network Communication | Versions number | Recommended areas for application |
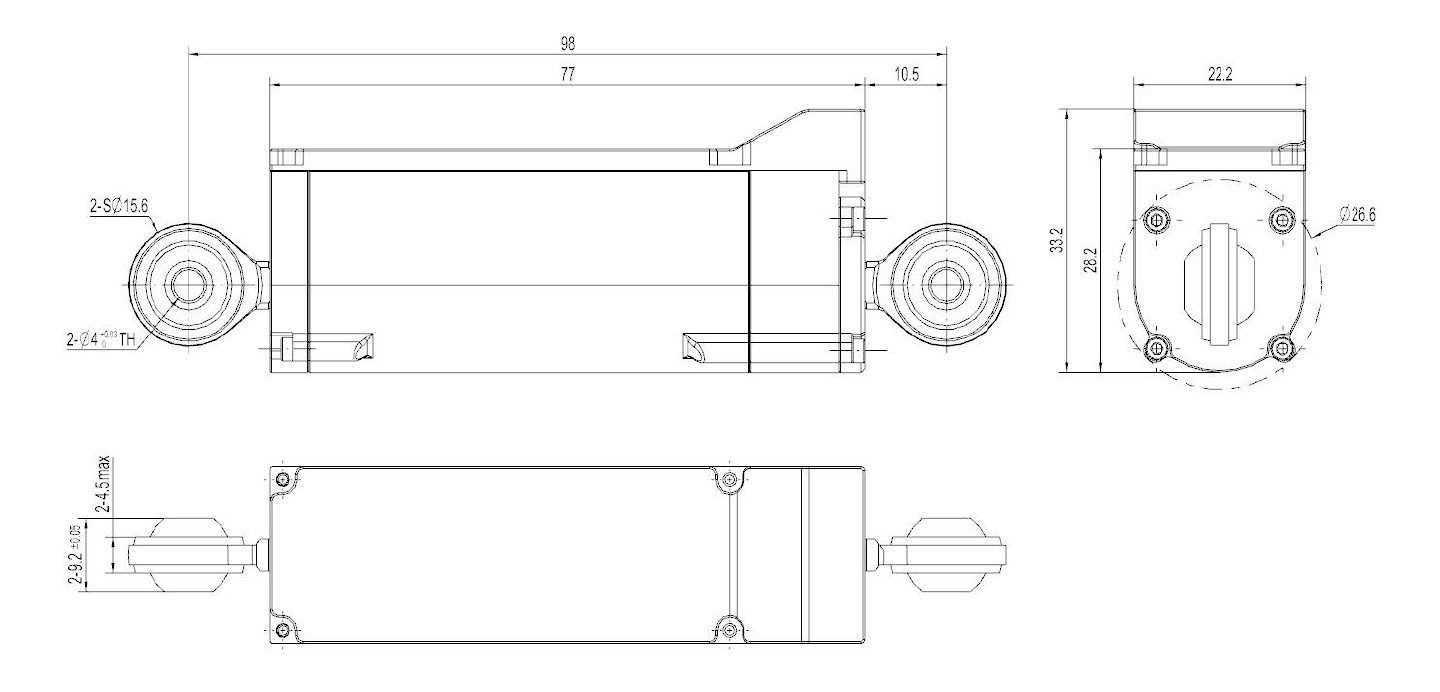
| V2.1-400N | 400N | 80mm/s | 29.4*100mm | 40mm | 0.16kg | Without | DC48±10% | CANFD/EtherCAT | V2.1 | Forearm |
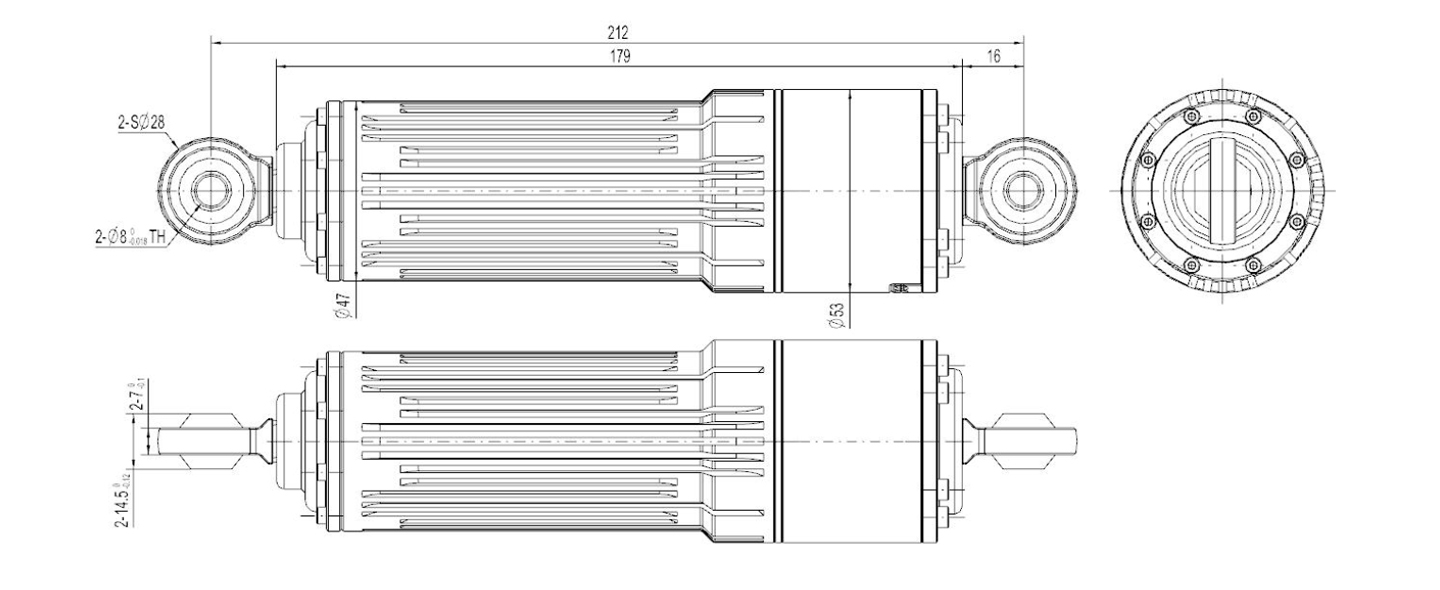
| V3-3900N | 3900N | 300mm/s | 50*315mm | 80mm | 1.2kg | Without | DC48±10% | CANFD/EtherCAT | V3 | Lower leg |
| V3-5000N | 5000N | 300mm/s | 50*244mm | 100mm | 1.4kg | Without | DC48±10% | CANFD/EtherCAT | V3 | Thigh |
| V1-150N | 150N | 40mm/s | 9.5*70.4mm | 10mm | 0.024kg | Without | DC48±10% | CANFD/EtherCAT | V1 | Dexterous hand |
| V1-2000N | 2000N | 150mm/s | 32*187mm | 80mm | 0.65kg | Without | DC48±10% | CANFD/EtherCAT | V1 | Waist |
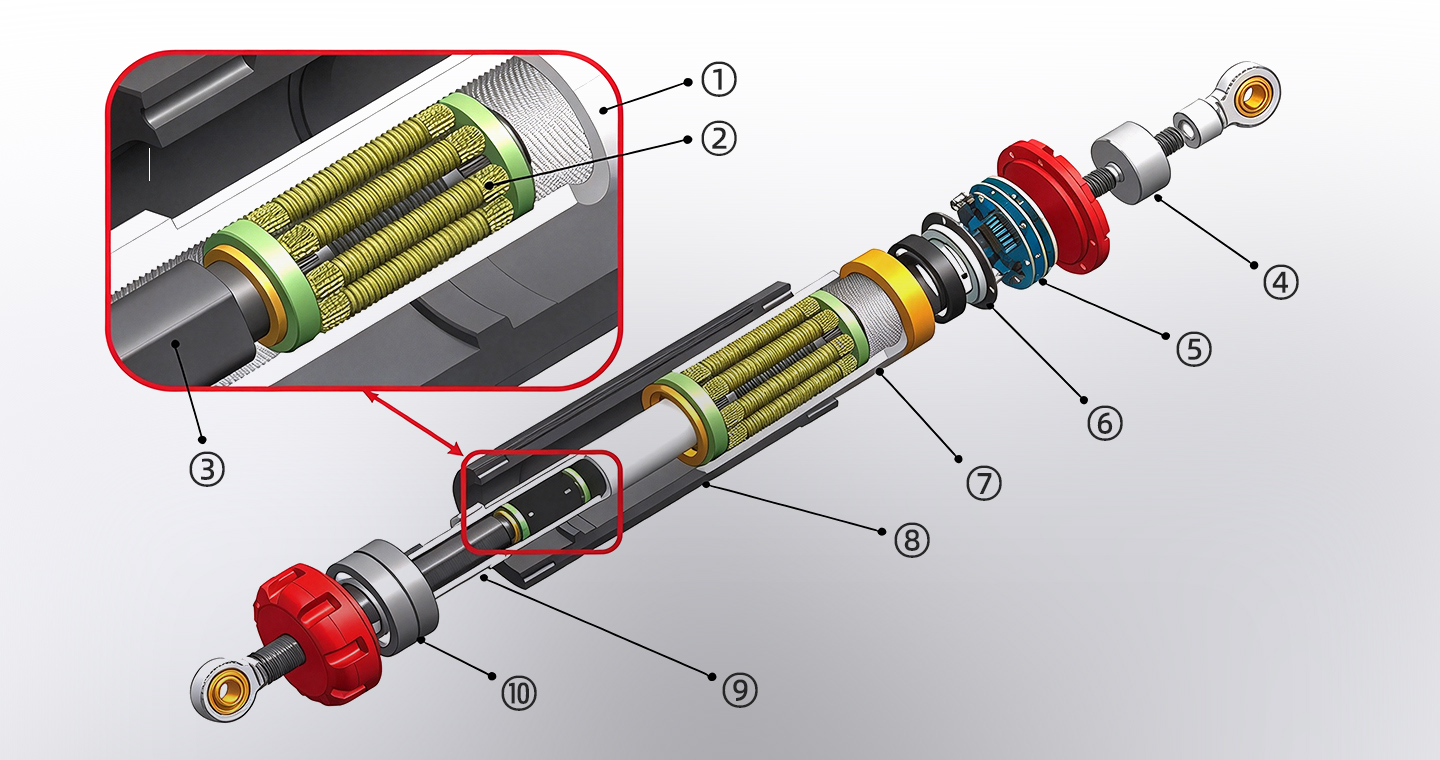
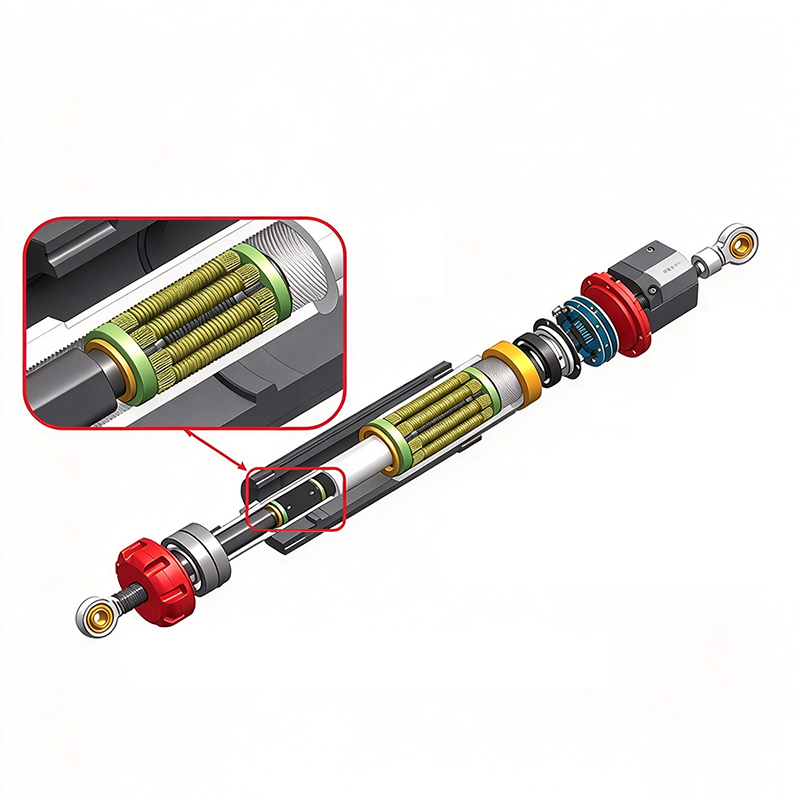
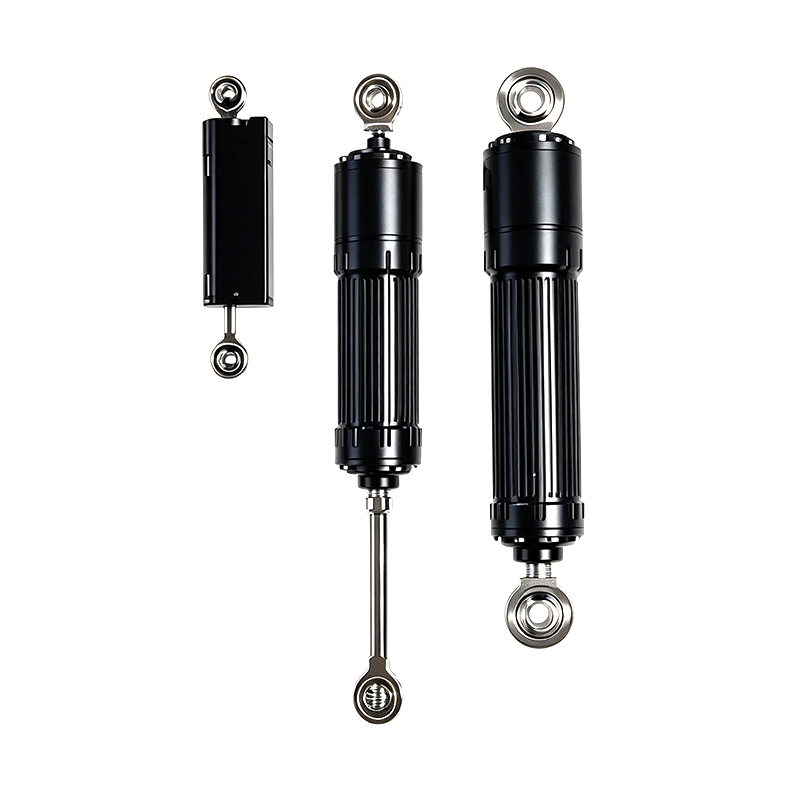
Linear-type joints utilize a "motor plus lead screw" configuration to directly generate push-pull force, offering a high capacity for force amplification. This high thrust density makes them exceptionally well-suited for high-load areas in humanoid robots, such as the lower limbs and knee joints.
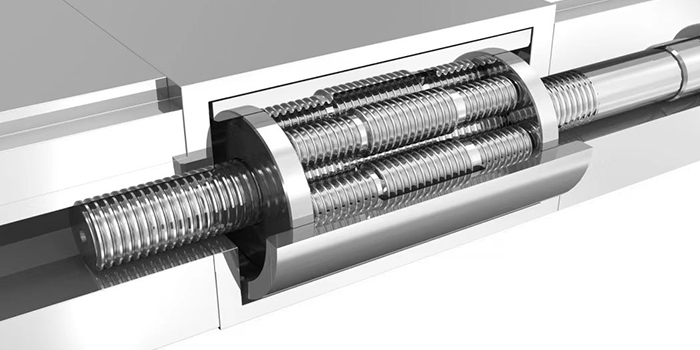
Equipped with planetary roller screws, the linear joint achieves micron-level position control. It offers a repeatability of better than ±0.02 mm, supporting high-precision, compliant motion and force-controlled interaction. Position feedback devices, such as Hall sensors, precisely monitor the actuator's position, velocity, and acceleration, enabling fine adjustment of the robot's locomotion posture and movement trajectory.
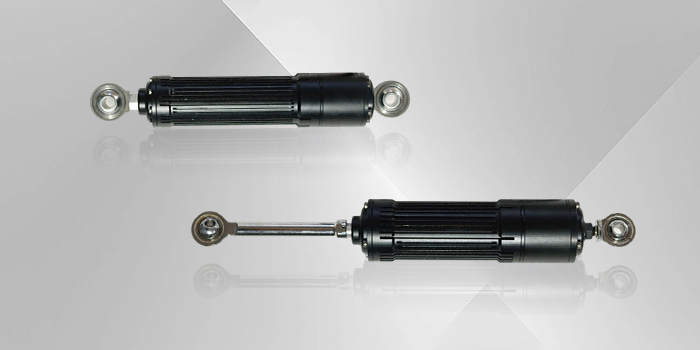
The integrated design incorporates drive, transmission, and sensing modules directly into the joint unit, eliminating the need for separate drive components. Compared to modular (decoupled) configurations, this integrated approach reduces the joint’s volume by 40%–60% and increases torque density by a factor of 2 to 3.
Linear drive mechanisms align more closely with the principles of biomimetics and offer a high energy-efficiency ratio, with forward-drive efficiency reaching over 80%. Furthermore, screw-drive systems excel in static holding capability; when combined with high-performance components and advanced manufacturing processes, these products can withstand demanding environmental conditions and ensure stable, long-term operation.
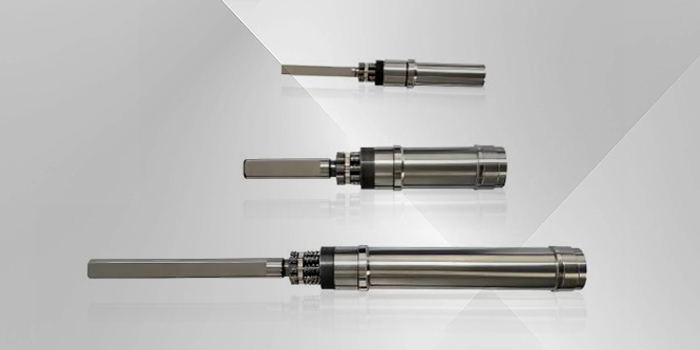
 V3-3900N
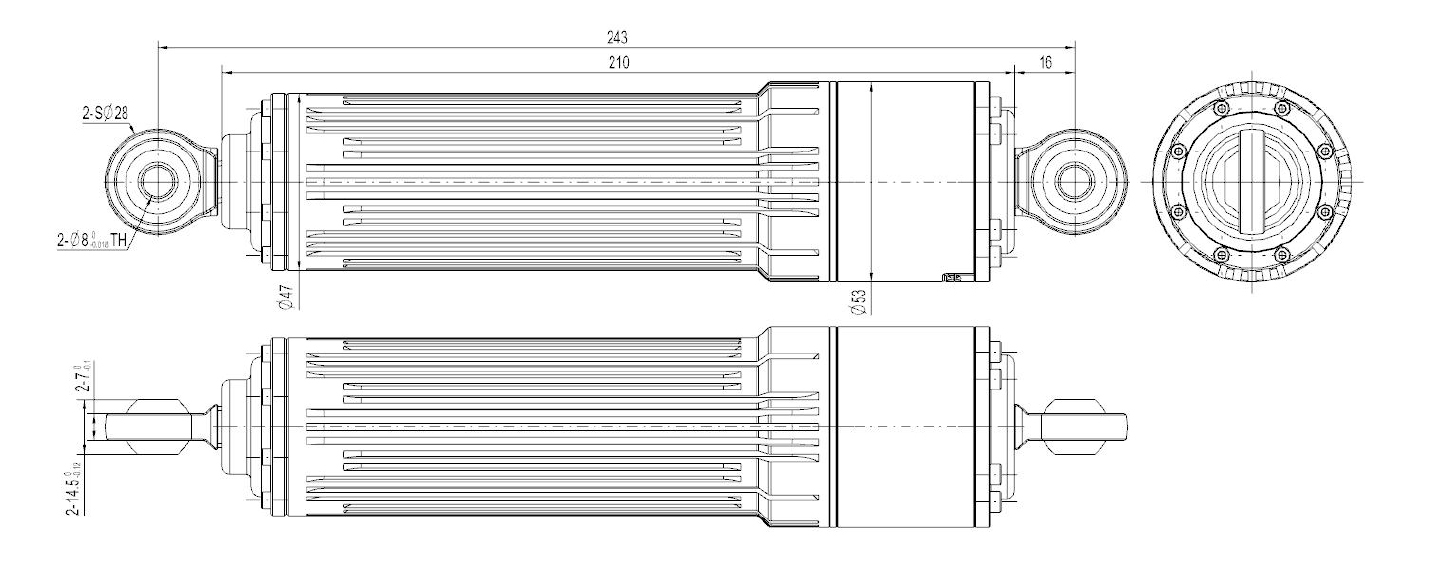 V3-500N
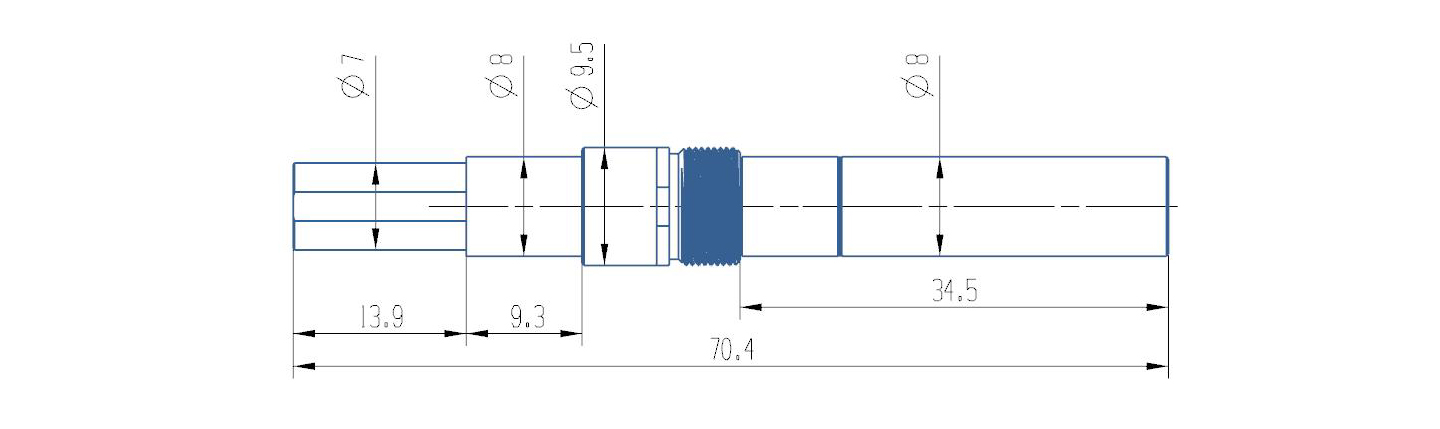 V1-150N
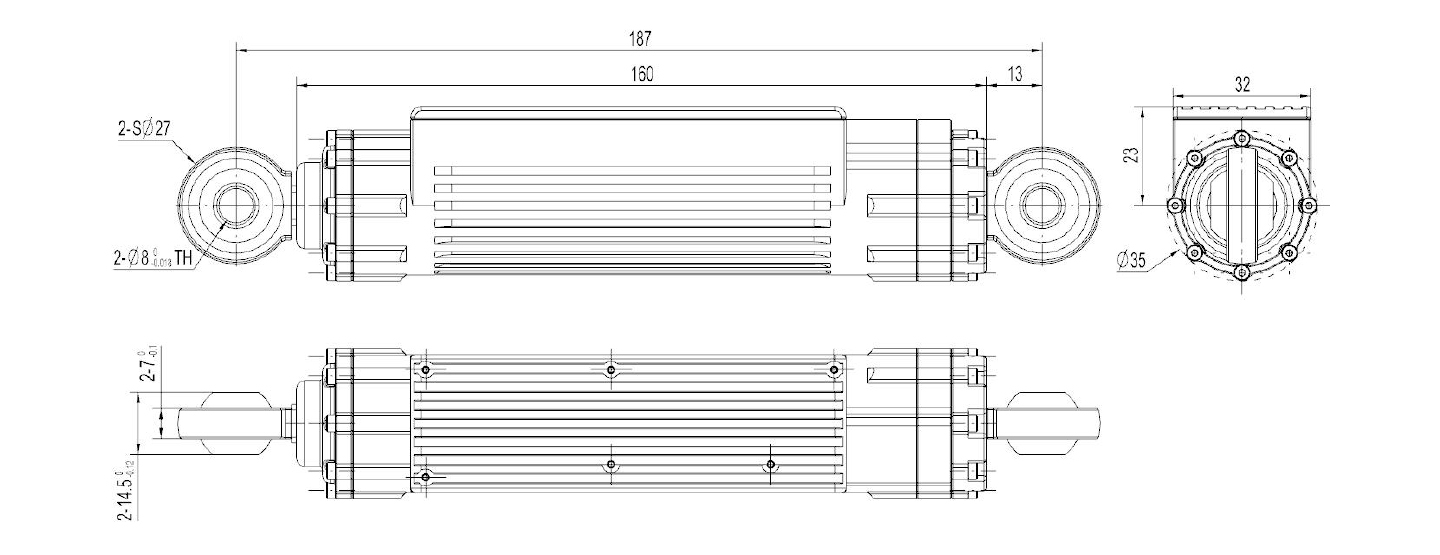 V1-2000N
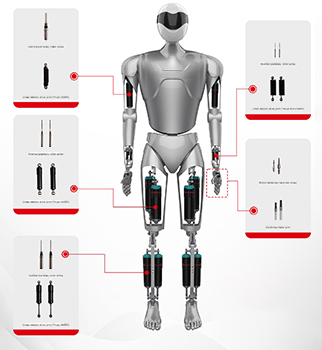
Humanoid robots
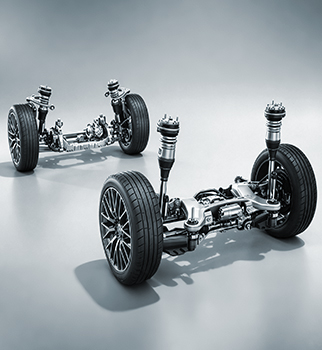
Automotive industry
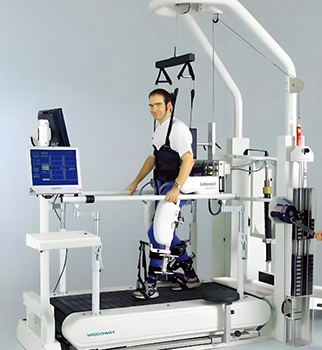
Medical and rehabilitation
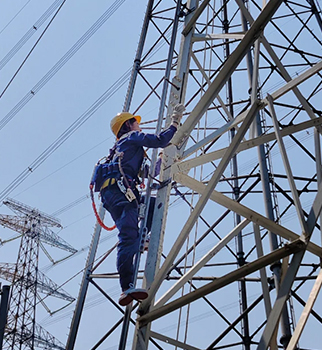
Specialized operations
| NO. | Max. Force(Standard Product) | Max. speed(Standard Product) | Size(Standard Product) | Stroke(Standard Product) | Weight(Standard Product) | Brake(Standard Product) | Rated voltage(Standard Product) | Network Communication | Pressure Sensor | Integrated Drive Controller | Versions number | Recommended areas for application |
| V2.1-400N | 400N | 80mm/s | 29.4*100mm | 40mm | 0.16kg | Without | DC48±10% | CANFD/EtherCAT | Yes | Yes | V2.1 | Forearm |
| V3-3900N | 3900N | 300mm/s | 50*315mm | 80mm | 1.2kg | Without | DC48±10% | CANFD/EtherCAT | Yes | Yes | V3 | Lower leg |
| V3-5000N | 5000N | 300mm/s | 50*244mm | 100mm | 1.4kg | Without | DC48±10% | CANFD/EtherCAT | Yes | Yes | V3 | Thigh |
| V1-150N | 150N | 40mm/s | 9.5*70.4mm | 10mm | 0.024kg | Without | DC48±10% | CANFD/EtherCAT | Yes | Yes | V1 | Dexterous hand |
| V1-2000N | 2000N | 150mm/s | 32*187mm | 80mm | 0.65kg | Without | DC48±10% | CANFD/EtherCAT | Yes | Yes | V1 | Waist |