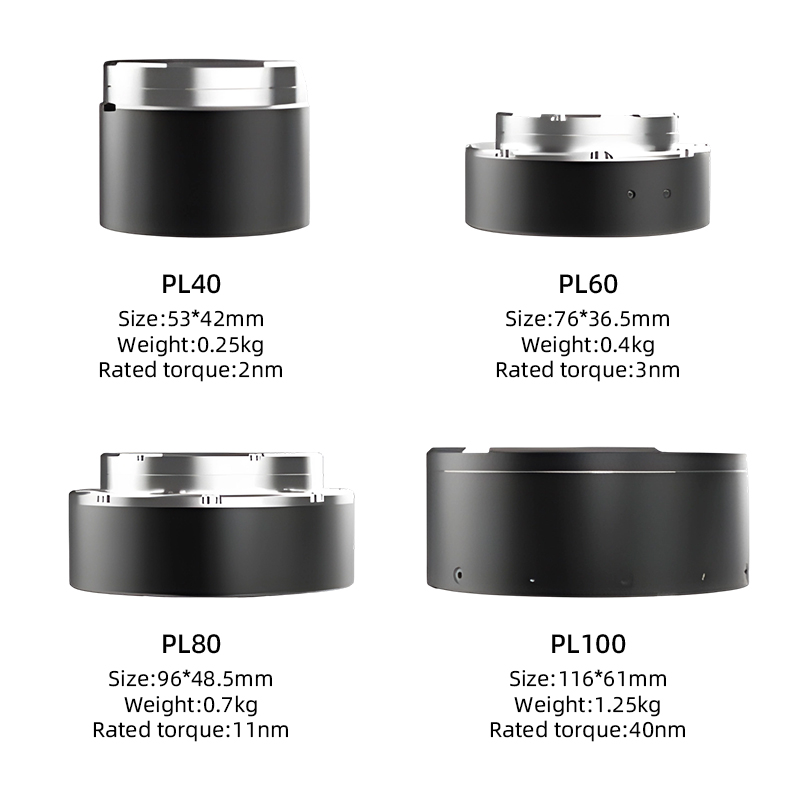
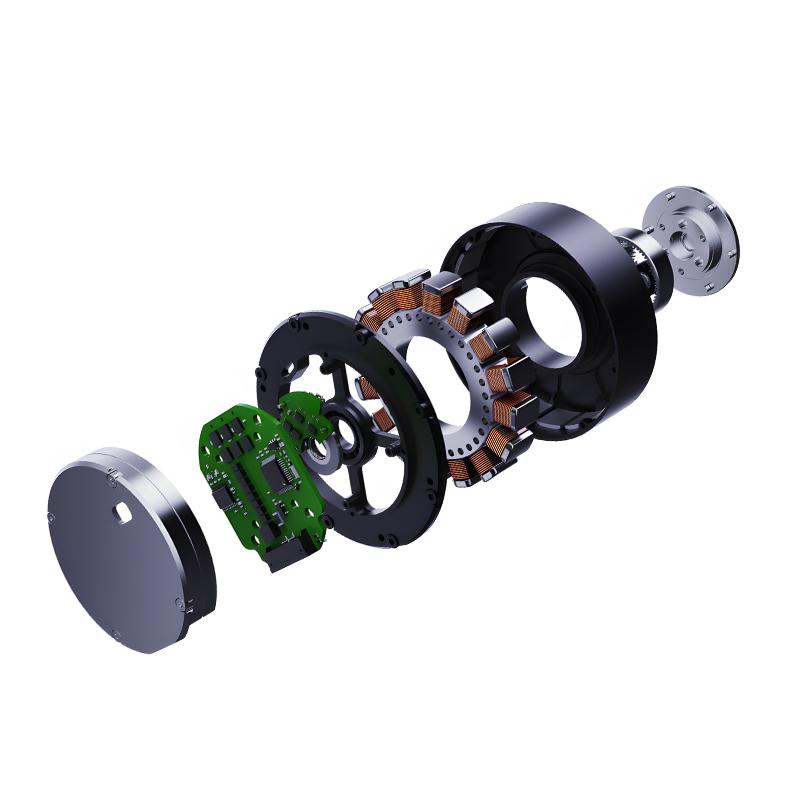
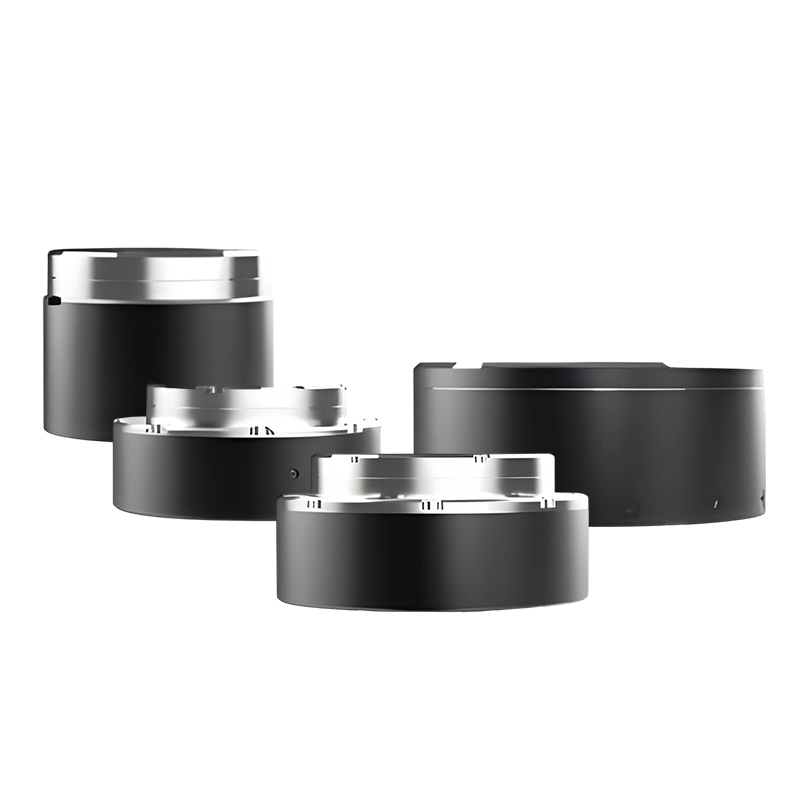
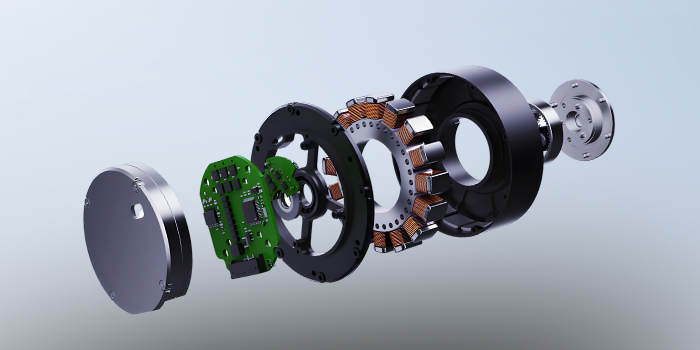
The PL series QDD planetary joint module is an integrated joint component comprising a high-torque-density motor, a low-reduction-ratio planetary gearbox, dual encoders, and a drive control system. By utilizing a low-reduction-ratio planetary gearbox, it achieves high-transparency force control, combining the compliance of direct drive with the high torque output of a gearbox.
Max rated torque: 96NM
Rated Speed : 50RPM
Rated Voltage: 48VDC
Communication: EtherCAT,CiA402 Protocol
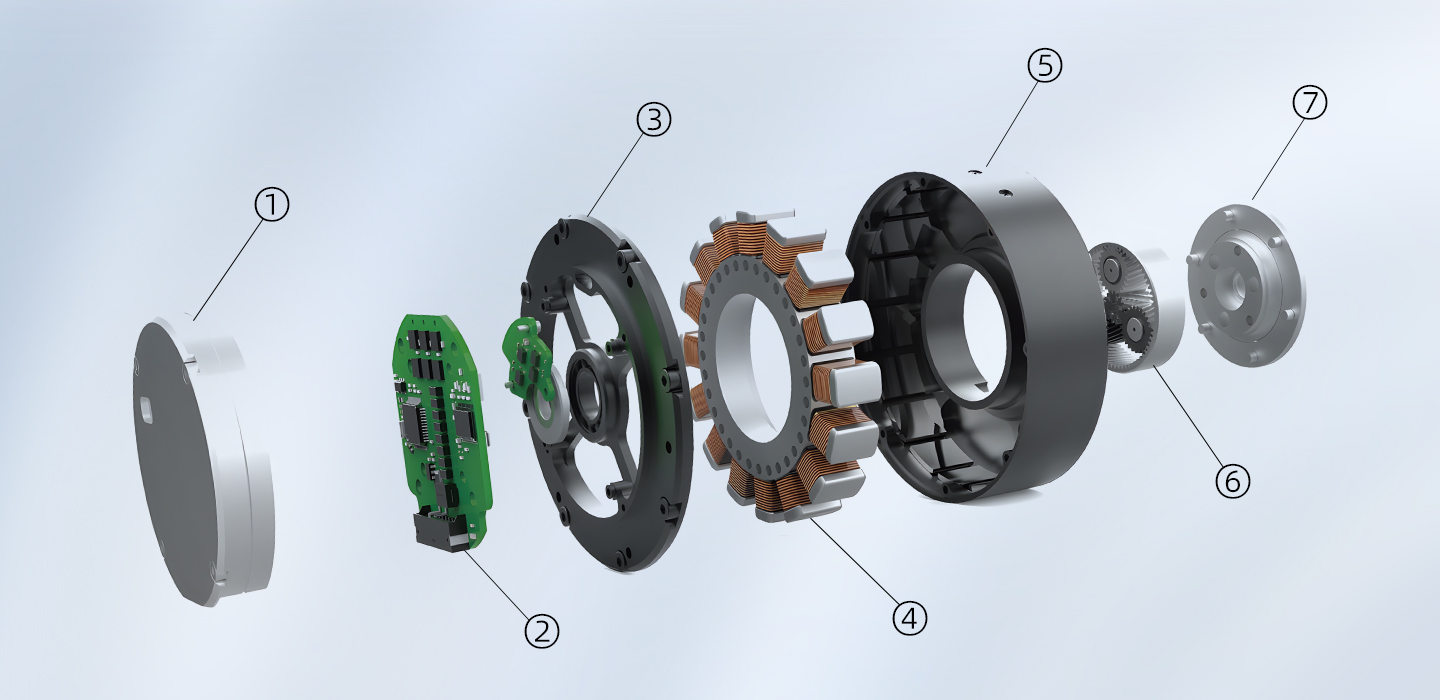
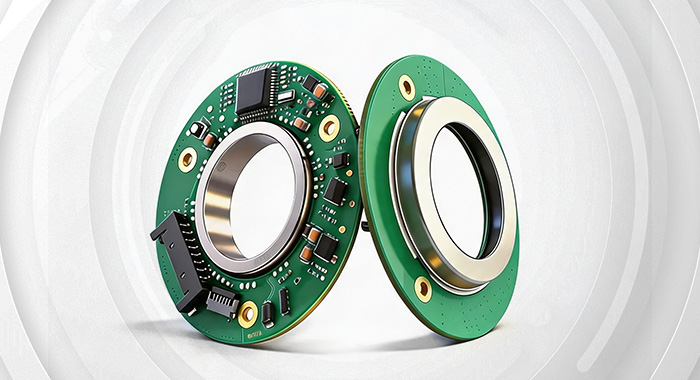
Flat, compact, impact-resistant quasi-direct-drive planetary joint module: thin-profile integrated design, high torque density, high backdrivability, and rugged planetary gearing for dynamic legged and collaborative robotic applications.
Low-inertia, high-precision quasi-direct-drive planetary joint module: lightweight rotor and optimized planetary reduction for fast dynamic response, combined with high-resolution encoding and rigid gearing for accurate positioning and transparent force control.
Backdrivable and intrinsically safe quasi-direct-drive planetary joint module: low-ratio QDD architecture enables external backdriving, transparent force sensing, and inherent compliance for safe human-robot interaction and collision-tolerant operation.
High-response quasi-direct-drive planetary joint module: low-inertia rotor and short transmission chain enable millisecond-level torque response, high-bandwidth force control, and stable dynamic tracking for legged and collaborative robotics.
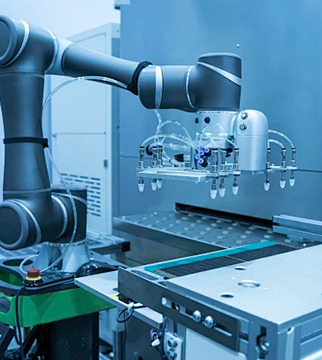
Humanoid Robots
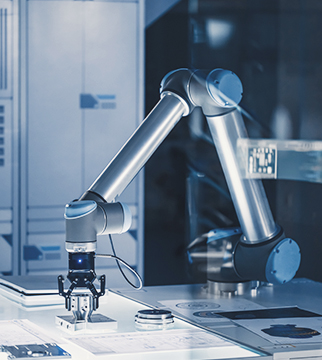
Exoskeletons/Wearable Devices
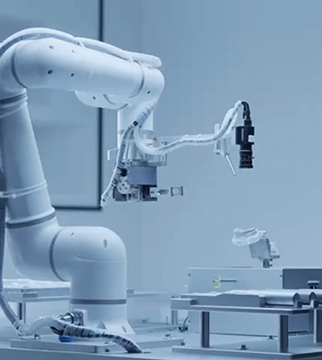
Rehabilitation Robots
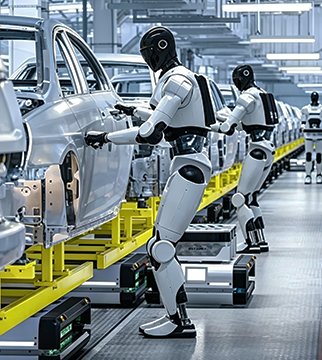
Teleoperation/Force Feedback
| Model | PL40 | PL60 | PL80 | PL100 |
| Rated torque (Nm) | 2 | 3 | 11 | 40 |
| Peak torque (Nm) | 4 | 6 | 22 | 80 |
| Maximum permissible instantaneous torque (N) | 6 | 9 | 33 | 120 |
| Rated speed (rpm) | 60 | 252 | 140 | 118 |
| Maximum speed (rpm) | 170 | 400 | 330 | 158 |
| Diameter (mm) | 53 | 76 | 96 | 116 |
| Length (mm) | 42 | 36.5 | 48.5 | 61 |
| Weight (kg) | 0.25 | 0.4 | 0.7 | 1.25 |
| Center through-hole diameter (mm) | n.a. | n.a. | n.a. | n.a. |
| Reduction ratio | 10 | 6 | 6 | 10 |

